

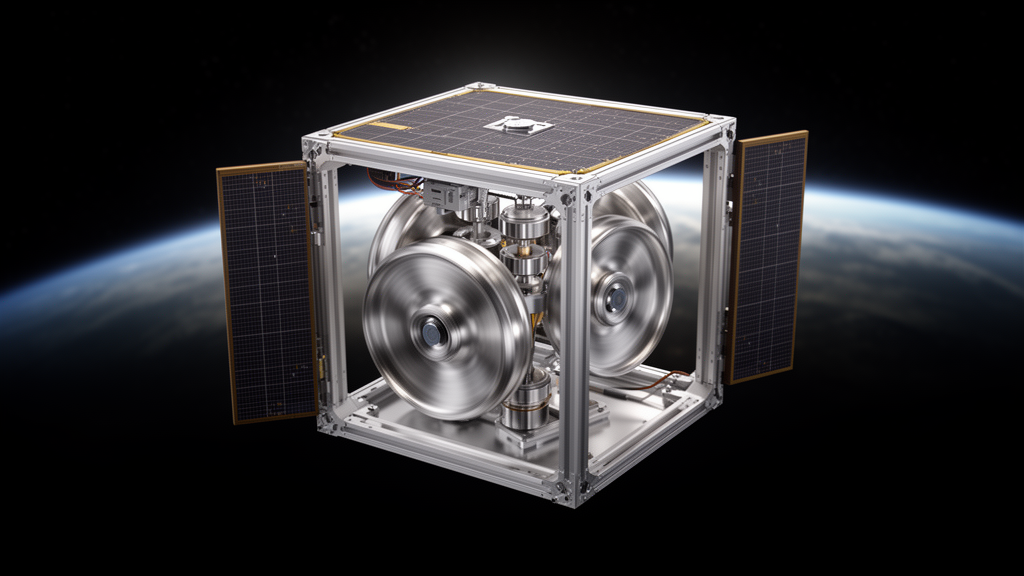
A new spacecraft architecture described in the International Journal of Aeronautical and Space Sciences proposes to steer small satellites in low Earth orbit without spending propellant. The concept, developed by Sajjad Hossain Masum and colleagues, replaces the familiar pyramid of reaction wheels with three independently driven toroidal rings mounted on mutually orthogonal bearing axes aligned with the spacecraft’s principal body axes. For a 6U-class platform of roughly 8.0 kilograms, the authors report that this arrangement delivers full-rank three-axis control authority purely through internal momentum exchange, and it preserves two-axis graceful degradation even if any single ring fails.
The motivation is a persistent engineering bottleneck. Conventional reaction-wheel pyramids and control moment gyro clusters progressively saturate under secular environmental torques. Once the wheels saturate, operators typically fire thrusters to dump accumulated momentum, which ties the attitude control budget directly to the propellant budget and constrains mission lifetime. According to the paper, the absence of a full-axis, propellant-free actuation solution co-validated with structural integrity constraints at the system level constitutes a critical gap at the small-satellite scale, and the three-ring design is offered as a candidate answer.
At the heart of the study is a ten-state nonlinear-coupled core-ring dynamic model derived from Newton-Euler principles. Because the rings exchange angular momentum with the satellite core while spinning, the resulting equations are strongly nonlinear and coupled, making the model the common plant against which both candidate controllers were tested. This shared plant allowed the authors to compare control strategies on an equal footing rather than relying on simplified decoupled approximations.
Two controllers were evaluated: a Lyapunov-stable proportional-derivative law as the baseline, and a boundary-layer sliding-mode controller designed to handle the nonlinear dynamics and model uncertainty. In simulated 10-degree step responses, the sliding-mode controller reduced settling time by 27 percent relative to the PD baseline and extended the closed-loop bandwidth fivefold.
The pointing advantage carried over to a more realistic scenario. On a simulated near-zenith pass over a ground target, with realistic sensor noise and a 15 percent perturbation in the assumed inertia properties, the sliding-mode controller maintained a 35 to 37 percent advantage in pointing error over the PD baseline. The authors emphasize that these figures come from simulation under stated perturbation levels, not from flight data, so they represent model-based performance expectations rather than demonstrated on-orbit results.
Because spinning rings impose centrifugal loads on their own structure, the team also examined whether the hardware could survive its own rotation rates. Finite-element analyses of the rings agreed with a closed-form centrifugal stress model to within 8 percent, a cross-check between numerical and analytical methods. At the 200 RPM science-mode ceiling, the computed von Mises safety factor was 387.8, indicating very large structural margins at the operating speeds considered for the science mode.
The combination of dynamics modeling, control design, and structural verification in a single framework is what the authors identify as the system-level contribution. Many propellant-free actuation concepts are validated only for control performance or only for structural feasibility; here the same architecture is carried through both analyses at the small-satellite scale.
The authors are explicit about the limits of the work. All results are simulation-based, and they state that hardware-in-the-loop and air-bearing testbed validation remain necessary before the architecture could be considered for flight qualification.
If those validation steps succeed, the three-ring concept could matter for the growing population of small satellites that need agile pointing but cannot afford the propellant mass of thruster-based desaturation. For now, the study establishes the analytical feasibility of the architecture: full three-axis, propellant-free actuation with structural margins computed at the system level, awaiting experimental confirmation.
Subject of Research: A three-ring momentum-exchange actuator architecture for propellant-free three-axis attitude control of small satellites in low Earth orbit
Article Title: A Three-Ring Momentum-Exchange Spacecraft Architecture: Nonlinear Dynamics, Structural Analysis, and Attitude Control for Small Satellite in LEO
Article References: Masum, S. H., Biyogo Nchama, V. A. O., Shi, P., Atib, M. M. A. A., Shoikot, S. M., & Rabby, M. F. (2026). A Three-Ring Momentum-Exchange Spacecraft Architecture: Nonlinear Dynamics, Structural Analysis, and Attitude Control for Small Satellite in LEO. International Journal of Aeronautical and Space Sciences. https://doi.org/10.1007/s42405-026-01297-2
Image Credits: AI Generated
DOI: 10.1007/s42405-026-01297-2
Keywords: small satellites, attitude control, reaction wheels, momentum exchange, sliding-mode control, low Earth orbit, spacecraft dynamics, finite-element analysis, propellant-free actuation, 6U CubeSat, Three-Ring, Momentum-Exchange
Cite Scienmag News
Grant Pearson. (October 23, 2026). Three-Ring Flywheel Design Promises Propellant-Free Attitude Control for Small Satellites. Scienmag. https://scienmag.com/three-ring-flywheel-design-promises-propellant-free-attitude-control-for-small-satellites/
Grant Pearson. "Three-Ring Flywheel Design Promises Propellant-Free Attitude Control for Small Satellites." Scienmag, 23 October 2026, https://scienmag.com/three-ring-flywheel-design-promises-propellant-free-attitude-control-for-small-satellites/. Accessed 23 October 2026.
Grant Pearson. "Three-Ring Flywheel Design Promises Propellant-Free Attitude Control for Small Satellites." Scienmag. October 23, 2026. https://scienmag.com/three-ring-flywheel-design-promises-propellant-free-attitude-control-for-small-satellites/


