

Sunday, November 1, 2026
Science
No Result
View All Result
  • Login
  • HOME
  • SCIENCE NEWS
  • CONTACT US
  • HOME
  • SCIENCE NEWS
  • CONTACT US
No Result
View All Result
Scienmag
No Result
View All Result
Home Science News Technology and Engineering

Research report: Efficient and compliant control framework for versatile human-humanoid collaborative transportation

October 28, 2026
in Technology and Engineering
Denise Maddox
By Denise Maddox Scienmag Editorial Profile - Mechanical Engineering
Reading Time: 2 mins read
0
Research report: Efficient and compliant control framework for versatile human-humanoid collaborative transportation

Research report: Efficient and compliant control framework for versatile human-humanoid collaborative transportation

65
SHARES
587
VIEWS
Share on FacebookShare on Twitter
ADVERTISEMENT

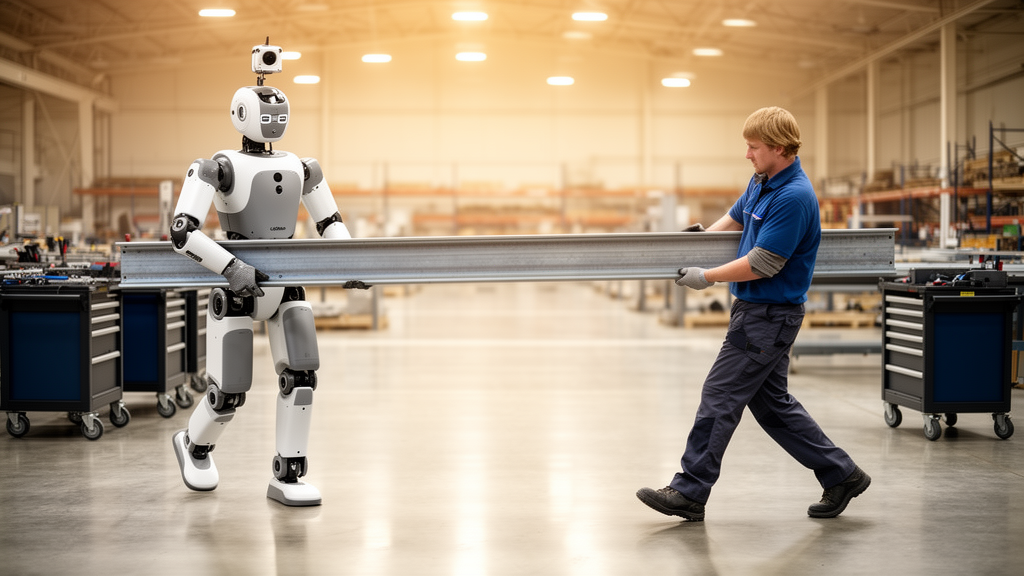
Engineers have demonstrated a control framework that lets a humanoid robot carry an object alongside a human partner, handling not only straight-line moves but also turns and curved, semi-circular paths of the kind that arise naturally when two agents share a load. The system was validated in real-world experiments on the Digit humanoid platform.

The framework rests on three components. A high-level planner generates dynamically feasible footstep plans by combining a model the researchers call the Interaction Linear Inverted Pendulum (I-LIP) with an admittance model and a model predictive control formulation. At the lowest level, a quadratic-programming-based whole-body controller executes those plans while accounting for the coupled dynamics of the humanoid and the object being carried together.

Between the two sits a stiffness modulation mechanism, which regulates the interaction between the robot and the object. Its role is to ensure convergence to a desired relative configuration, defined by the distance between the object and the robot’s center of mass.

To measure how well the collaboration actually works, the team proposes an efficiency metric that captures both task performance and inter-agent coordination. According to the authors, this metric highlights the role of compliance in collaborative tasks and offers insights into desirable trajectory characteristics across both the high- and low-level control layers.

The reported behaviors include translation, turning, and combined motions such as semi-circular trajectories, demonstrating versatility beyond simple point-to-point carrying. Because the planner explicitly supports both translational and rotational motion, the framework targets the full range of movements fundamental to co-transport scenarios rather than a single scripted task.

The I-LIP planner and the coupled-dynamics whole-body controller are designed to handle exactly that coupling between balance and shared load.

Subject of Research: A control framework enabling humanoid robots to collaboratively transport objects with human partners, validated on the Digit platform.

Article Title: Efficient and compliant control framework for versatile human-humanoid collaborative transportation

Article References: Kumbhar, S. S., Kulkarni, A. M., & Artemiadis, P. (2026). Efficient and compliant control framework for versatile human-humanoid collaborative transportation. Autonomous Robots, 50(4), Article 45. https://doi.org/10.1007/s10514-026-10271-6

Image Credits: AI Generated

DOI: 10.1007/s10514-026-10271-6

Keywords: humanoid robots, collaborative transportation, human-robot interaction, compliant control, I-LIP, whole-body control, stiffness modulation, Digit, model predictive control, co-transport, Efficient, compliant

Cite Scienmag News

Denise Maddox. (October 28, 2026). Research report: Efficient and compliant control framework for versatile human-humanoid collaborative transportation. Scienmag. https://scienmag.com/research-report-efficient-and-compliant-control-framework-for-versatile-human-humanoid-collaborative-transportation/


Denise Maddox. "Research report: Efficient and compliant control framework for versatile human-humanoid collaborative transportation." Scienmag, 28 October 2026, https://scienmag.com/research-report-efficient-and-compliant-control-framework-for-versatile-human-humanoid-collaborative-transportation/. Accessed 1 November 2026.

Denise Maddox. "Research report: Efficient and compliant control framework for versatile human-humanoid collaborative transportation." Scienmag. October 28, 2026. https://scienmag.com/research-report-efficient-and-compliant-control-framework-for-versatile-human-humanoid-collaborative-transportation/

Tags: admittance control models for robotsco-transportcollaborative transportationcompliance and efficiency metrics in human-robot taskscompliantcompliant controlDigitDigit humanoid platform experimental validationdynamic footstep planning for humanoidsefficienthuman-robot interactionhuman-robot interaction control frameworkHumanoid robot collaborative transportationhumanoid robotsI-LIPInteraction Linear Inverted Pendulum (I-LIP)model predictive controlmodel predictive control for humanoidsreal-world humanoid experimentsstiffness modulationstiffness modulation in humanoid collaborationversatile humanoid robot navigationwhole-body controlwhole-body robot control
Share26Tweet16
Previous Post

Nanowire Nano-Vaccine Drives Balanced Immune Response and Prophylactic Tumor Protection in Mice

Next Post

Psychobiotics and Polyphenols May Modulate the Gut-Brain Axis in Mental Health, Review Finds

Related Posts

Systematic review maps sustainability tensions in offshore wind development
Climate

Systematic review maps sustainability tensions in offshore wind development

October 30, 2026
Amateur maps and sketches helped put Hong Kong’s wartime pillboxes on official charts
Archaeology

Amateur maps and sketches helped put Hong Kong’s wartime pillboxes on official charts

October 30, 2026
Heavier logging trucks only pay off when the road network lets them work
Technology and Engineering

Heavier logging trucks only pay off when the road network lets them work

October 30, 2026
Supersulfated cement outperforms Portland cement in curbing concrete’s alkali-silica reaction
Technology and Engineering

Supersulfated cement outperforms Portland cement in curbing concrete’s alkali-silica reaction

October 30, 2026
Heritage remade: how three Gulf districts turn patrimonialisation into cultural tourism
Technology and Engineering

Heritage remade: how three Gulf districts turn patrimonialisation into cultural tourism

October 30, 2026
Patch Shuffling Trick Makes Adversarial Attacks on Vision Transformers Far More Transferable
Technology and Engineering

Patch Shuffling Trick Makes Adversarial Attacks on Vision Transformers Far More Transferable

October 30, 2026
Next Post
Psychobiotics and Polyphenols May Modulate the Gut-Brain Axis in Mental Health, Review Finds

Psychobiotics and Polyphenols May Modulate the Gut-Brain Axis in Mental Health, Review Finds

  • Mothers who receive childcare support from maternal grandparents show more optimized

    Mothers who receive childcare support from maternal grandparents show more parental warmth, finds NTU Singapore study

    27656 shares
    Share 11059 Tweet 6912
  • University of Seville Breaks 120-Year-Old Mystery, Revises a Key Einstein Concept

    1061 shares
    Share 424 Tweet 265
  • Bee body mass, pathogens and local climate influence heat tolerance

    682 shares
    Share 273 Tweet 171
  • Researchers record first-ever images and data of a shark experiencing a boat strike

    546 shares
    Share 218 Tweet 137
  • Groundbreaking Clinical Trial Reveals Lubiprostone Enhances Kidney Function

    531 shares
    Share 212 Tweet 133
Science

Embark on a thrilling journey of discovery with Scienmag.com—your ultimate source for cutting-edge breakthroughs. Immerse yourself in a world where curiosity knows no limits and tomorrow’s possibilities become today’s reality!

RECENT NEWS

  • Trademarks Meet Patents in New Method to Spot Technology Opportunities
  • Reddit self-declarations offer auditable labels for demographic inference
  • Scots pine needles map trace element pollution in Polish industrial town
  • Dual-blockchain scheme secures vehicle handovers without pre-shared keys

Categories

  • Agriculture
  • Anthropology
  • Archaeology
  • Athmospheric
  • Biology
  • Biotechnology
  • Blog
  • Bussines
  • Cancer
  • Chemistry
  • Climate
  • Earth Science
  • Editorial Policy
  • Marine
  • Mathematics
  • Medicine
  • Pediatry
  • Policy
  • Psychology & Psychiatry
  • Science Education
  • Science News
  • Social Science
  • Space
  • Technology and Engineering

Subscribe to Blog via Email

Enter your email address to subscribe to this blog and receive notifications of new posts by email.

Join 5,150 other subscribers

© 2025 Scienmag - Science Magazine

Welcome Back!

Login to your account below

Forgotten Password?

Retrieve your password

Please enter your username or email address to reset your password.

Log In
No Result
View All Result
  • HOME
  • SCIENCE NEWS
  • CONTACT US

© 2025 Scienmag - Science Magazine

Discover more from Science

Subscribe now to keep reading and get access to the full archive.

Continue reading




