


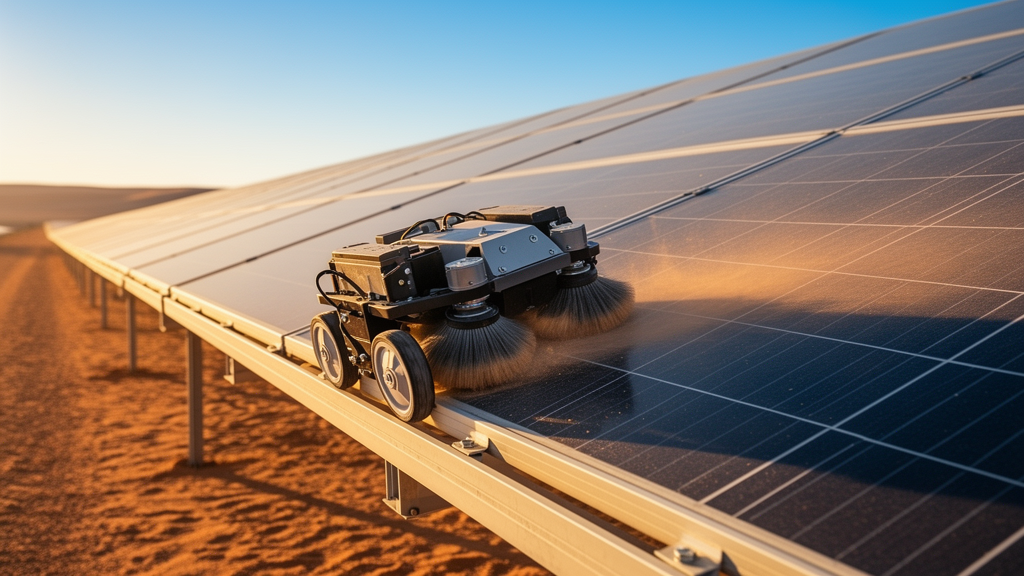
Solar farms live and die by the amount of sunlight their panels can capture, and even a thin film of dust can shave measurable percentages off a photovoltaic array’s output. That is why cleaning robots that crawl across panel surfaces have become an increasingly common sight at utility-scale installations, particularly in arid regions where soiling losses accumulate quickly. But keeping a robot moving smoothly across a field of glass is a harder control problem than it might appear. A new study published in Scientific Reports presents a simulation of a servo control system for photovoltaic cleaning robots that tackles the problem head-on, using multi-motor synchronization and precise pulse-width modulation to keep the machines steady, straight, and jam-free under difficult conditions.
The research, conducted by a team of engineers at CGN (Guizhou) New Energy in Guiyang, China, addresses a deceptively simple failure mode. A photovoltaic cleaning robot does not rely on a single motor; its walking and cleaning functions depend on several motors working in concert. When those motors fall out of step, the consequences are immediate and visible. Speeds drift apart, phases deviate, and under complex working conditions the robot begins to jam in its motion or clean unevenly, leaving streaks of dust across panels that were supposed to emerge spotless. Traditional control strategies, the authors note, are particularly prone to these asynchronous behaviors when the robot encounters disturbances on the panel surface.
To understand why synchronization matters so much, it helps to picture what a cleaning robot actually does. It must traverse long rows of tilted panels, maintain a consistent heading so it does not wander off the glass, and drive brushes or cleaning elements at a steady rate so that every square meter receives the same treatment. If the motors on one side spin slightly faster than those on the other, the robot yaws; if the cleaning motors lag behind the drive motors, the coverage becomes patchy. Each of these errors compounds over the length of a panel row, which means that small deviations at the start of a pass can become significant defects by the end of it. The engineering challenge, therefore, is not just to make the robot move, but to make all of its motors behave as a single, coordinated system.
The core of the new approach is a path tracking control strategy built around error components. Rather than commanding the robot’s motors directly from a precomputed trajectory, the system continuously calculates how far the robot has strayed from its desired path and feeds those errors back into the control loop. The robot’s linear velocity is regulated by a proportional-integral controller, commonly known as a PI controller, which combines an immediate response to the current error with an accumulating term that eliminates steady-state offsets over time. The yaw rate, meanwhile, is governed by a proportional controller, or P controller, which reacts to heading errors in proportion to their magnitude. Together, these two controllers allow the robot to both stay on its intended line and correct its orientation, achieving accurate tracking of the desired path even when external forces push it off course.
The second pillar of the system is precise pulse-width modulation, or PWM, the technique by which the controller adjusts motor speed. PWM works by switching a DC power supply on and off in rapid pulses; the fraction of each cycle spent in the on state, known as the duty cycle, determines how much average power reaches the motor and, consequently, how fast it turns. By varying the duty cycle of the DC pulse sequence with fine granularity, the control system can make minute adjustments to each motor’s speed in real time. This precision is what allows the synchronization scheme to work: when one motor begins to drift relative to its partners, the controller can nudge its duty cycle up or down until the speeds realign, all without the abrupt corrections that would cause jerky motion on the fragile glass surface of a solar panel.
The simulation results reported in the paper offer a quantitative picture of how well the scheme performs. Under disturbance conditions, the deflection angle of the photovoltaic cleaning robot, the measure of how far its heading has been knocked away from the intended direction, returns to the expected value of 0 radians. In other words, the robot does not merely reduce its heading error; it eliminates it, recovering its original orientation after being perturbed. This recovery behavior is critical for real-world deployment, where gusts of wind, uneven panel frames, and debris on the glass can all act as disturbances that would send a poorly controlled robot veering off its path.
Equally important are the synchronization results. The time delay data for multi-motor synchronous control remained relatively low throughout the experiments, fluctuating between 0.46 seconds and 1.43 seconds. Those figures demonstrate, according to the authors, the system’s capability to effectively correct synchronization errors among motors. In practical terms, this means that when one motor falls behind, the control system detects and compensates for the discrepancy within a window of roughly half a second to a second and a half, fast enough to prevent the drift from accumulating into a jam or a visible cleaning defect. For a machine that must complete long passes over hundreds of panels, keeping synchronization errors bounded at this level is the difference between a robot that finishes its route cleanly and one that has to be rescued midway.
The broader context for this work is the rapid expansion of photovoltaic capacity in regions where water is scarce and dust is abundant. Cleaning robots offer a way to maintain panel efficiency without the enormous water consumption of manual washing, and their reliability directly affects the economics of solar power. A robot that jams or cleans unevenly requires human intervention, eroding the labor savings that justify its deployment. By improving the fundamental control layer, the servo system that governs how the robot’s motors cooperate, this research aims to make autonomous cleaning dependable enough for continuous, unattended operation. The simulation framework also provides a testing ground where control strategies can be refined before they are exposed to the cost and risk of physical trials on live solar arrays.
It is worth emphasizing what the study delivers and what it does not. The published results come from simulation, a standard and necessary stage in control system development that allows engineers to validate algorithms, tune controller gains, and stress-test the system against disturbances in a controlled environment. The demonstration that deflection angles return to zero and that synchronization delays stay within a bounded range is evidence that the proposed strategy is sound, but translating simulation performance into field performance will depend on how faithfully the simulated motor dynamics, panel surfaces, and disturbance profiles match reality. The authors describe the work as a simulation of the servo control system, positioning it as a foundation for the control architecture rather than a finished field-ready product.
Nevertheless, the study highlights a trend that is easy to overlook amid the glamour of large-scale renewable energy: the quiet importance of control engineering. The energy transition is often narrated through headline figures, gigawatts of capacity, falling costs per watt, record efficiency percentages, but the day-to-day performance of solar infrastructure depends on countless small engineering problems being solved well. Keeping a robot’s motors in lockstep as it crawls across a dusty panel in the sun is one of those problems, and the combination of PI-based velocity control, proportional yaw correction, and precise PWM duty-cycle adjustment offers a concrete, tested answer. As solar farms spread into ever dustier and more remote environments, the machines that keep their panels clean will need exactly this kind of coordination to do their work reliably, one synchronized revolution at a time.
Subject of Research: Servo control simulation for photovoltaic cleaning robots using multi-motor synchronization and precise PWM control
Article Title: Simulation of servo control system for photovoltaic cleaning robot based on multi-motor synchronization and precise PWM control
Article References: Shi, Y., Huang, K., Wang, F., Zhao, F., & Wang, K. (2026). Simulation of servo control system for photovoltaic cleaning robot based on multi-motor synchronization and precise PWM control. Scientific Reports. https://doi.org/10.1038/s41598-026-73455-1
Image Credits: AI Generated
DOI: 10.1038/s41598-026-73455-1
Keywords: photovoltaic cleaning robot, multi-motor synchronization, PWM control, servo control system, path tracking, PI controller, P controller, solar panel cleaning, duty cycle, robotics, renewable energy, Scientific Reports
Cite Scienmag News
Denise Maddox. (October 15, 2026). Synchronized Motors and Precision PWM Keep Solar Panel Cleaning Robots on Track. Scienmag. https://scienmag.com/synchronized-motors-and-precision-pwm-keep-solar-panel-cleaning-robots-on-track/
Denise Maddox. "Synchronized Motors and Precision PWM Keep Solar Panel Cleaning Robots on Track." Scienmag, 15 October 2026, https://scienmag.com/synchronized-motors-and-precision-pwm-keep-solar-panel-cleaning-robots-on-track/. Accessed 15 October 2026.
Denise Maddox. "Synchronized Motors and Precision PWM Keep Solar Panel Cleaning Robots on Track." Scienmag. October 15, 2026. https://scienmag.com/synchronized-motors-and-precision-pwm-keep-solar-panel-cleaning-robots-on-track/


