
Saturday, September 5, 2026
Science
No Result
View All Result
  • Login
  • HOME
  • SCIENCE NEWS
  • CONTACT US
  • HOME
  • SCIENCE NEWS
  • CONTACT US
No Result
View All Result
Scienmag
No Result
View All Result
Home Science News Technology and Engineering

KAIST Creates Robot That Perceives Environment and Moves Like Animals

July 16, 2026
in Technology and Engineering
Denise Maddox
By Denise Maddox Scienmag Editorial Profile - Mechanical Engineering
Reading Time: 2 mins read
0
KAIST Creates Robot That Perceives Environment and Moves Like Animals

KAIST Creates Robot That Perceives Environment and Moves Like Animals

65
SHARES
587
VIEWS
Share on FacebookShare on Twitter
ADVERTISEMENT

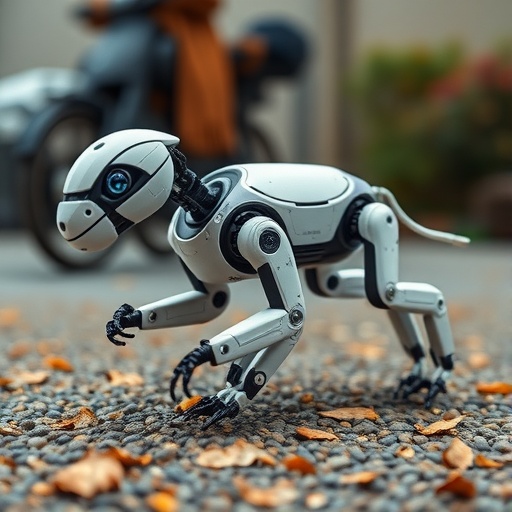
An era where robots can decide for themselves how to move outdoors is taking shape. KAIST has unveiled a quadrupedal robot control system that lets a single agent choose the most suitable locomotion mode—walking, running, jumping, and more—while conditions change in real time. Instead of following a fixed routine, the robot adapts gait as it encounters stairs, gaps, ledges, and uneven forest trails.

The core challenge is that “fast” is not enough in the wild. Real environments combine obstacles in unpredictable 3D configurations, making it difficult for conventional four-legged robots to maintain both speed and stability. Many existing systems still treat each gait as a separate control problem, limiting smooth transitions when terrain abruptly shifts.

To address this, the KAIST team introduced APT-RL (Action Pretrained Transformer-based Reinforcement Learning). The method is designed to first acquire a library of locomotion skills and then seamlessly blend and switch among them during deployment. The result is a controller capable of integrating multiple movement primitives into one continuous decision process.

Training did not rely on motion capture. Instead, the researchers generated 15.5 hours of simulated training data covering diverse gaits in only eight minutes. The robot learned from simulated physics using robot dynamics models and trajectory optimization, enabling efficient acquisition of basic movement capabilities without recording human or animal motion.

After pretraining, reinforcement learning shaped an autonomous policy that selects gaits appropriate for complex terrain. With perception inputs, the robot can respond to obstacles across stairs, ledges, and gaps, selecting actions that preserve balance while meeting target speed requirements.

The system combines a depth camera and LiDAR to obtain three-dimensional information about the surroundings. This sensor fusion supports real-time recognition of nearby structures and allows the controller to match locomotion strategy to both terrain geometry and desired velocity.

Experiments were conducted on the team’s robot, “KAIST HOUND.” Tests included indoor obstacle courses and real outdoor routes around KAIST campus and forest trails, where the robot navigated irregular surfaces such as roots, fallen branches, and leaf-covered paths.

Performance results highlight both agility and stability. In rugged terrain, KAIST HOUND achieved a peak instantaneous speed of about six meters per second (roughly 22 km/h) while adapting gait on the fly. The robot demonstrated autonomous transitions between trot and bound and integrated walking, running, jumping, and ledge-clearing within a unified controller.

The researchers describe the work as a foundational step toward physical-AI quadrupeds that can operate in rugged settings. They point to future impact in disaster response, defense missions, and industrial inspections where reliable locomotion under uncertainty is essential.

Keywords

quadrupedal robots, locomotion skills, reinforcement learning, perception, LiDAR, depth camera, real-world agility, gait switching, trajectory optimization, physical-AI

Subject of Research: Quadrupedal robot multi-skill locomotion control for real outdoor environments
Article Title: Agile perceptive multi-skill locomotion for quadrupedal robots in the wild
News Publication Date: 16-Jul (announced); published July 15, 2026 (U.S. Eastern time)
Web References: http://dx.doi.org/10.1126/scirobotics.adz7397
References:

Article Title: KAIST Creates Robot That Perceives Environment and Moves Like Animals

Article References: Original research article

Image Credits: AI Generated

DOI: Not provided

Keywords: adaptive gait transition, AI-powered animal-like robots, autonomous outdoor mobility, multi-gait robotic control, obstacle navigation in robotics, quadrupedal robot locomotion, real-time environment perception, reinforcement learning for robotics, seamless movement control, simulation-based robot training, terrain adaptability in robots, transformer-based reinforcement learning

Cite Scienmag News

Denise Maddox. (July 16, 2026). KAIST Creates Robot That Perceives Environment and Moves Like Animals. Scienmag. https://scienmag.com/kaist-creates-robot-that-perceives-environment-and-moves-like-animals/

Denise Maddox. "KAIST Creates Robot That Perceives Environment and Moves Like Animals." Scienmag, 16 July 2026, https://scienmag.com/kaist-creates-robot-that-perceives-environment-and-moves-like-animals/. Accessed 5 September 2026.

Denise Maddox. "KAIST Creates Robot That Perceives Environment and Moves Like Animals." Scienmag. July 16, 2026. https://scienmag.com/kaist-creates-robot-that-perceives-environment-and-moves-like-animals/


Tags: adaptive gait transitionAI-powered animal-like robotsautonomous outdoor mobilitymulti-gait robotic controlobstacle navigation in roboticsquadrupedal robot locomotionreal-time environment perceptionreinforcement learning for roboticsseamless movement controlsimulation-based robot trainingterrain adaptability in robotstransformer-based reinforcement learning
Share26Tweet16
Previous Post

Black Women Need Greater Support to Access Breast Cancer Screening

Next Post

Long-Chain Omega-3 Supplementation Shapes Gut Microbiota in Extremely Preterm Infants

Related Posts

Rapid method predicts propeller aircraft noise levels in communities
Technology and Engineering

Rapid method predicts propeller aircraft noise levels in communities

September 5, 2026
How robots navigate social mini-games: definitions, taxonomy, and algorithms
Technology and Engineering

How robots navigate social mini-games: definitions, taxonomy, and algorithms

September 5, 2026
Kagome metals enable goniopolar transverse thermoelectric effects via Fermiology
Technology and Engineering

Kagome metals enable goniopolar transverse thermoelectric effects via Fermiology

September 5, 2026
Exciton condensate defect-bound states mirror Yu-Shiba-Rusinov physics
Technology and Engineering

Exciton condensate defect-bound states mirror Yu-Shiba-Rusinov physics

September 5, 2026
Measuring elastic barriers that block molecular glass rearrangements
Technology and Engineering

Measuring elastic barriers that block molecular glass rearrangements

September 5, 2026
Retinomorphic sensor adapts optoelectronic computing through multiple stimulus responses
Technology and Engineering

Retinomorphic sensor adapts optoelectronic computing through multiple stimulus responses

September 5, 2026
Next Post
Long-Chain Omega-3 Supplementation Shapes Gut Microbiota in Extremely Preterm Infants

Long-Chain Omega-3 Supplementation Shapes Gut Microbiota in Extremely Preterm Infants

  • Mothers who receive childcare support from maternal grandparents show more optimized

    Mothers who receive childcare support from maternal grandparents show more parental warmth, finds NTU Singapore study

    27656 shares
    Share 11059 Tweet 6912
  • University of Seville Breaks 120-Year-Old Mystery, Revises a Key Einstein Concept

    1061 shares
    Share 424 Tweet 265
  • Bee body mass, pathogens and local climate influence heat tolerance

    682 shares
    Share 273 Tweet 171
  • Researchers record first-ever images and data of a shark experiencing a boat strike

    546 shares
    Share 218 Tweet 137
  • Groundbreaking Clinical Trial Reveals Lubiprostone Enhances Kidney Function

    531 shares
    Share 212 Tweet 133
Science

Embark on a thrilling journey of discovery with Scienmag.com—your ultimate source for cutting-edge breakthroughs. Immerse yourself in a world where curiosity knows no limits and tomorrow’s possibilities become today’s reality!

RECENT NEWS

  • Jaw bone death risk in osteoporosis patients on antiresorptive drugs
  • Rapid method predicts propeller aircraft noise levels in communities
  • How robots navigate social mini-games: definitions, taxonomy, and algorithms
  • Frontiers of Environmental Science Celebrates Top Papers of 2025

Categories

  • Agriculture
  • Anthropology
  • Archaeology
  • Athmospheric
  • Biology
  • Biotechnology
  • Blog
  • Bussines
  • Cancer
  • Chemistry
  • Climate
  • Earth Science
  • Editorial Policy
  • Marine
  • Mathematics
  • Medicine
  • Pediatry
  • Policy
  • Psychology & Psychiatry
  • Science Education
  • Social Science
  • Space
  • Technology and Engineering

Subscribe to Blog via Email

Enter your email address to subscribe to this blog and receive notifications of new posts by email.

Join 5,151 other subscribers

© 2025 Scienmag - Science Magazine

Welcome Back!

Login to your account below

Forgotten Password?

Retrieve your password

Please enter your username or email address to reset your password.

Log In
No Result
View All Result
  • HOME
  • SCIENCE NEWS
  • CONTACT US

© 2025 Scienmag - Science Magazine

Discover more from Science

Subscribe now to keep reading and get access to the full archive.

Continue reading