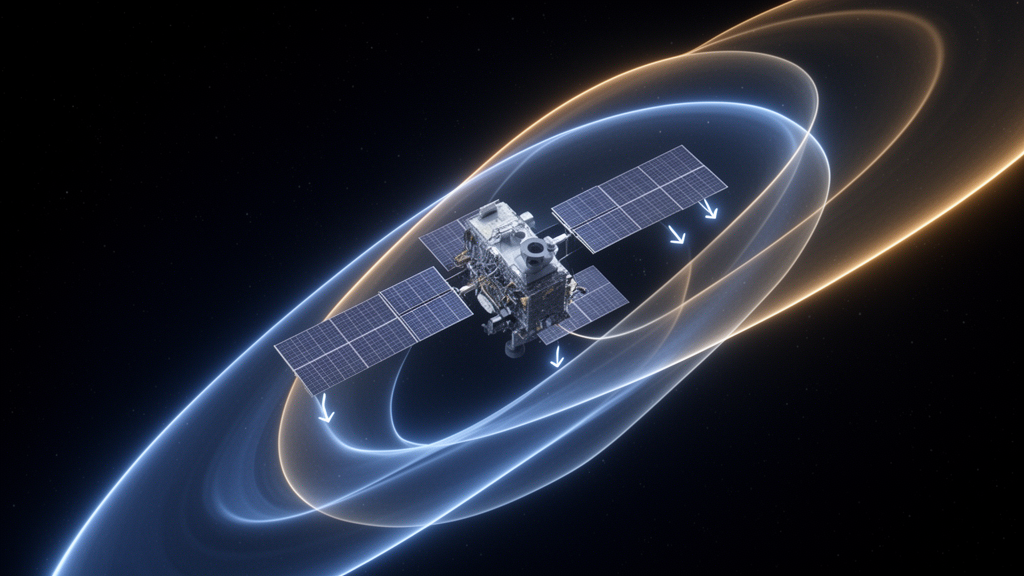
Spacecraft rarely enjoy gentle conditions. A satellite slewing toward a new target must contend with uncertain inertia properties, environmental disturbance torques, actuator imperfections, and the fact that rotations simply do not live on a flat space. A new study published in Frontiers in Robotics and AI tackles this problem with a mathematically ambitious tool: a super-twisting control law formulated intrinsically on Lie groups, the curved mathematical spaces on which rotational motion naturally evolves. The work, led by Pierantonio Bertuccio with Mauro Mancini and Elisa Capello of Politecnico di Torino, extends a general geometric sliding-mode framework so that a higher-order, continuous reaching mechanism can be built directly into the geometry itself rather than bolted on afterward for one specific spacecraft model.
The motivation begins with a representation problem. Describing attitude with Euler angles introduces kinematic singularities at certain orientations, while unit quaternions are nonsingular but redundant and suffer from a double covering that can cause the notorious unwinding phenomenon, in which a spacecraft rotates the long way around to reach a nearby attitude. Rotation matrices avoid both pitfalls, but they evolve on the nonlinear manifold SO(3), the group of three-dimensional rotations. Geometric control embraces this structure by formulating dynamics and control laws directly on the configuration manifold, preserving its nonlinear character without auxiliary local coordinates. Yet geometric consistency alone does not guarantee robustness against model uncertainty and external disturbances, which is where sliding-mode control enters the picture.
Conventional first-order sliding-mode control drives trajectories to a prescribed sliding set and rejects matched perturbations, but its discontinuous control action produces high-frequency switching. Higher-order sliding-mode methods move the discontinuity into a higher derivative or an internal controller state. Among them, the Super-Twisting Algorithm stands out because, under suitable regularity assumptions, it establishes a second-order sliding regime while producing a continuous ideal control input, without requiring explicit knowledge of the sliding-variable derivative. Its theoretical foundations are well established in Euclidean spaces, but existing geometric super-twisting designs have been tailored to specific configuration groups or particular applications, such as spacecraft attitude on SO(3) or rotorcraft and quadrotor designs.
The new contribution fills that gap by formulating a multivariable super-twisting reaching mechanism directly within a general Lie-group mechanical framework, building on an existing state-space Lie-group and sliding-subgroup construction for fully actuated mechanical systems. Both layers of the reaching dynamics are expressed on the Lie algebra, the tangent space at the group identity, through covariant derivatives associated with the mechanical metric and its Levi-Civita connection. This means the controller respects the curvature of the configuration space at every step, rather than importing Euclidean formulas through an auxiliary parametrization. The discontinuous terms are defined through an intrinsic set-valued sign map induced by the inertia metric, and the closed-loop dynamics are interpreted as a differential inclusion with Filippov solutions, which makes the discontinuous term well defined even at the sliding surface.
The theoretical core is a strict Lyapunov analysis carried out covariantly. The authors establish finite-time convergence to the second-order sliding set, derive constructive nominal and robust gain conditions, and provide explicit upper bounds on the reaching time. In the nominal case, the sliding variable and its internal compensating state converge to zero in finite time, so the error trajectory reaches the sliding subgroup. When a matched disturbance acts through the same channel as the control input and satisfies a stated bound on its covariant derivative, the internal super-twisting state compensates it in finite time, yielding exact rejection of the disturbance. Once the sliding condition is reached and remains invariant, the inherited reduced dynamics ensure almost-global asymptotic tracking of the desired trajectory. The authors are careful to note that the topological limitations of SO(3) are not removed: continuous time-invariant feedback cannot globally stabilize a single attitude equilibrium, so the tracking guarantee remains almost global rather than global.
To demonstrate the framework, the team specialized it to rigid-spacecraft attitude dynamics on SO(3), deriving an explicit commanded body torque for a fully actuated spacecraft with a redundant four-reaction-wheel assembly in a symmetric pyramidal configuration, subject to torque and angular-momentum constraints and an actuation delay of 0.01 seconds. In a comparative simulation over a 1500-second horizon, the proposed Super-Twisting Geometric Sliding-Mode Controller was pitted against two first-order geometric sliding-mode benchmarks using the same attitude sliding variable, so the comparison isolated the reaching mechanism itself. All three controllers drove a large initial attitude error toward the desired trajectory under a bounded sinusoidal disturbance torque, but their character differed sharply in the transient and in residual oscillations.
The discontinuous benchmark produced the most evident high-frequency switching activity, while the continuous first-order approximation reduced that behavior at the price of converging only to a neighborhood of the sliding manifold. The proposed controller delivered a similarly smooth actuator command without the steady-state accuracy degradation. Quantitatively, evaluated over the steady-state window excluding the reaching transient, the super-twisting controller showed the smallest steady-state errors and residual oscillations of the three; relative to the discontinuous benchmark, the angular-velocity root-mean-square error and its largest component-wise peak-to-peak oscillation were both reduced by approximately a factor of 41, with a comparable reduction for the sliding variable. The equivalent-control residual, which should vanish when the internal state fully compensates the matched disturbance, settled into a small oscillatory neighborhood of zero after the transient, consistent with the theoretical prediction under the discrete implementation.
Beyond the single comparison, the authors ran two numerical campaigns totaling 700 long-duration simulations, with the controller updated at 10 Hz and the commanded torque held between updates by a zero-order hold. In a fixed-gain Monte Carlo robustness study of 400 trials, initial attitudes were drawn uniformly at random, inertia matrices were perturbed within physically admissible ranges, and the actuator model included multiplicative gain uncertainty, additive noise, and component-wise torque saturation. Every trial reached the practical sliding neighborhood and satisfied the maneuver-settling criterion, a 100 percent success rate within the considered uncertainty envelope. The median reaching time was 18.95 seconds with a 95th percentile of 30.91 seconds, while the median complete maneuver-settling time was 97.74 seconds, confirming that finite-time reaching of the sliding neighborhood precedes full attitude tracking. The median steady-state pointing error was 0.01271 degrees, and no torque-saturation event occurred in the campaign.
A separate gain-sensitivity study, using a single reproducible off-nominal scenario with common random numbers so every candidate gain faced identical conditions, mapped the trade-offs in tuning. Increasing the first super-twisting gain reduced the median reaching time almost monotonically, from 75.75 seconds in the low band to 13.30 seconds in the high band, but at the cost of higher control effort, rising from 7.65 to 9.23 newton-meter-seconds, and larger peak torque and residual angular-rate activity. The second gain had a comparatively weak influence on reaching time over the tested interval, changing the median from 24.80 to 23.40 seconds, while gradually increasing control effort and angular-rate error. The practical guidance that follows is to choose the first gain large enough to satisfy the robust feasibility margin and then adjust the second to meet reaching-time requirements while monitoring actuator demand.
The authors are explicit about the limits of these guarantees. The finite-time reaching and exact matched-disturbance compensation results are continuous-time theoretical statements that hold under full-actuation, matching, and disturbance-regularity assumptions; the sampled-data simulations demonstrate practical convergence to small residual neighborhoods and reduced oscillatory activity, not a complete elimination of discretization-induced chattering or an extension of the theory beyond its assumptions. The specialization to SO(3) also retains the almost-global rather than global character of the tracking result, and the Monte Carlo campaigns used different numerical settings from the controller comparison, so their results are complementary rather than directly comparable. Future work, the team notes, should extend the framework toward underactuated and unmatched-disturbance settings and validate it in more realistic spacecraft-control environments. For now, the study offers a rigorous bridge between abstract differential geometry and a very practical engineering nuisance: keeping a spacecraft pointed precisely, without rattling its own hardware to do it.
Subject of Research: An intrinsic super-twisting sliding-mode control law formulated on Lie groups and applied to spacecraft attitude tracking
Article Title: Intrinsic geometric super-twisting control on Lie groups with application to spacecraft attitude tracking
Article References: Bertuccio, P., Mancini, M., & Capello, E. (2026). Intrinsic geometric super-twisting control on Lie groups with application to spacecraft attitude tracking. Frontiers in Robotics and AI, 13, Article 1961299. https://doi.org/10.3389/frobt.2026.1961299
Image Credits: AI Generated
DOI: 10.3389/frobt.2026.1961299
Keywords: spacecraft attitude control, super-twisting algorithm, sliding-mode control, Lie groups, geometric control, finite-time convergence, disturbance rejection, Lyapunov analysis, SO(3), reaction wheels, sampled-data control, Monte Carlo simulation
Cite Scienmag News
Denise Maddox. (October 28, 2026). Continuous Super-Twisting Control on Curved Spaces Promises Smoother Spacecraft Attitude Tracking. Scienmag. https://scienmag.com/continuous-super-twisting-control-on-curved-spaces-promises-smoother-spacecraft-attitude-tracking/
Denise Maddox. "Continuous Super-Twisting Control on Curved Spaces Promises Smoother Spacecraft Attitude Tracking." Scienmag, 28 October 2026, https://scienmag.com/continuous-super-twisting-control-on-curved-spaces-promises-smoother-spacecraft-attitude-tracking/. Accessed 28 October 2026.
Denise Maddox. "Continuous Super-Twisting Control on Curved Spaces Promises Smoother Spacecraft Attitude Tracking." Scienmag. October 28, 2026. https://scienmag.com/continuous-super-twisting-control-on-curved-spaces-promises-smoother-spacecraft-attitude-tracking/