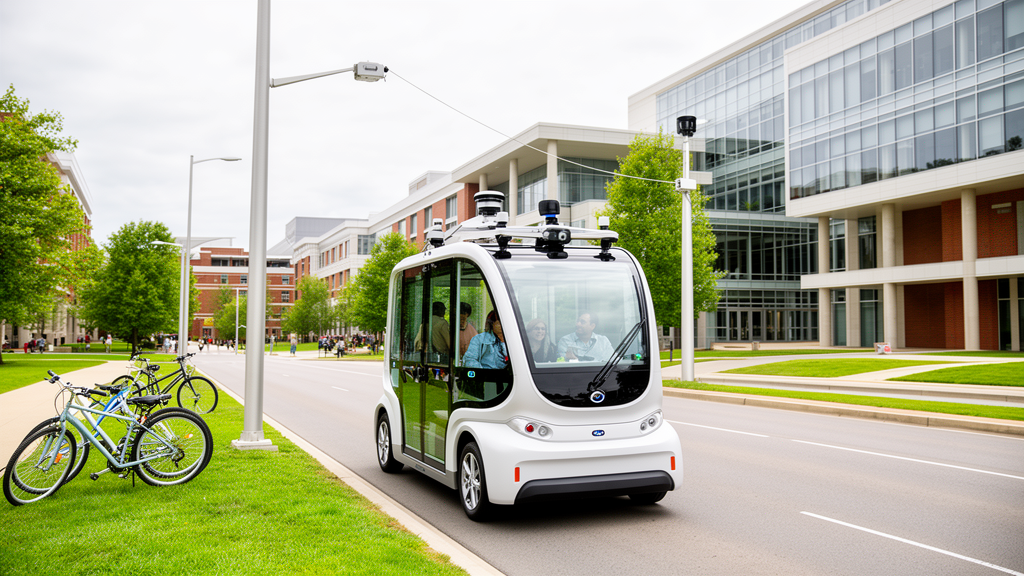
Researchers at Graz University of Technology, working with partners in China, have developed an autonomous, on-demand shuttle service designed to operate without a fixed timetable. The project combines a battery-powered vehicle carrying up to 15 people with sensors and connected road infrastructure to support flexible mobility in real traffic. A test vehicle is already operating on a test route in China, while demonstrators are planned in Austria. The service is intended to bridge the convenience of private cars with the shared capacity of public transport, but the release does not report measured reductions in emissions, travel times or safety incidents.
The shuttle uses lidar, radar and cameras to observe its surroundings and communicate through 5G with smart infrastructure, including cameras placed near difficult or blind sections of road. According to the project team, this collaborative perception can extend the vehicle’s awareness of pedestrians and cyclists beyond what its onboard sensors can detect directly. The approach is intended to support safe autonomous control by giving the shuttle additional information about potentially vulnerable road users. If the network connection fails, the vehicle has an independent safety function that brings it to a controlled stop.
Before deployment, researchers validated the vehicles’ safety concept through computational simulations that recreated real streetscapes, including buildings and infrastructure. The virtual environments were used to examine algorithms for route planning, object detection and the behavior of other road users in both extreme and everyday scenarios. The project team says millions of simulated kilometres were needed because autonomous driving requires extensive testing across a very large number of situations. These simulations are a pre-deployment validation method; they do not by themselves establish the shuttle’s performance under real-world operating conditions.
To increase the flexibility of the service, the Chinese research partners developed a dynamic optimization system for routes and charging processes. Its stated goals are to reduce passenger waiting times and maximize vehicle capacity utilization, with the aim of operating the shuttle efficiently within a wider route network. The system is also intended to support higher-capacity sharing, in which several passengers travel together in one electric vehicle rather than making separate journeys in private cars. The release presents reduced emissions, improved air quality and more efficient use of road space as potential benefits, but it provides no operational data with which to quantify those outcomes.
The project brings together TU Graz, Tongji University, Wenzhou University and the Chinese company Seisys, with funding from the Austrian Research Promotion Agency FFG. Graz University of Technology identifies computational simulation and modeling as the project’s research method, while the vehicle and connected-infrastructure system provide the basis for real-world testing. The announcement describes a technology-development program with a Chinese test route and planned Austrian demonstrators, rather than a completed service evaluation. Its central technical feature is the combination of onboard sensing, cooperative communication with infrastructure and virtual testing across millions of simulated kilometres.
Subject of Research: Development and simulation testing of an autonomous, sensor-linked on-demand public transport shuttle.
Article Title: Personalized public transport: Graz University of Technology develops autonomous mobility service
Article References: Personalized public transport: Graz University of Technology develops autonomous mobility service. Original publication (Bibliographic details unavailable.)
Image Credits: AI Generated
DOI: Not provided
Keywords: autonomous vehicles, on-demand transport, public mobility, lidar sensing, collaborative perception, 5G infrastructure, computational simulation, electric shuttle, TU Graz, Personalized, public, transport
Cite Scienmag News
Denise Maddox. (October 22, 2026). TU Graz develops sensor-linked autonomous on-demand shuttle service. Scienmag. https://scienmag.com/tu-graz-develops-sensor-linked-autonomous-on-demand-shuttle-service/
Denise Maddox. "TU Graz develops sensor-linked autonomous on-demand shuttle service." Scienmag, 22 October 2026, https://scienmag.com/tu-graz-develops-sensor-linked-autonomous-on-demand-shuttle-service/. Accessed 22 October 2026.
Denise Maddox. "TU Graz develops sensor-linked autonomous on-demand shuttle service." Scienmag. October 22, 2026. https://scienmag.com/tu-graz-develops-sensor-linked-autonomous-on-demand-shuttle-service/