


New Framework Uses Language Models to Evaluate Autonomous Vehicle Traffic Intelligence
Researchers at Tongji University have developed an evaluation framework combining large language models and neural networks to assess how intelligently ...
Researchers at Tongji University have developed an evaluation framework combining large language models and neural networks to assess how intelligently ...

Researchers from Southeast University and Monash University have developed a physics-informed control framework combining sensor fusion, model predictive control, and ...

An inaugural editorial in AI Perspectives outlines the journal's mandate to explore artificial intelligence applications, societal readiness, and theoretical frontiers ...

Researchers propose a specialized data space framework to securely harmonize intra-vehicular sensor data and advance autonomous driving algorithms across diverse ...
A qualitative study of 27 Saudi experts and citizens finds that autonomous vehicle readiness in smart cities depends on physical ...
A simulation study shows a safety-constrained nonlinear model predictive controller can keep a virtual autonomous vehicle within road boundaries during ...

A modular path-planning framework called LKSD-PRRT* achieved a 100% static planning success rate and cut dynamic recovery time by 77.25% ...
A simulation study proposes an arithmetic-angle street network called Taigyoun Space, in which autonomous vehicles could in principle move continuously ...
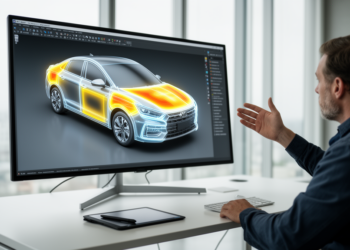
A Unity-based simulation of fifteen vehicles under fifty-seven scenarios finds that wheels, front fenders, and headlights are the surfaces most ...
A new evidence synthesis proposes a taxonomy linking autonomous-vehicle interaction factors to human driver errors, finding unsafe behavior concentrated in ...


Embark on a thrilling journey of discovery with Scienmag.com—your ultimate source for cutting-edge breakthroughs. Immerse yourself in a world where curiosity knows no limits and tomorrow’s possibilities become today’s reality!