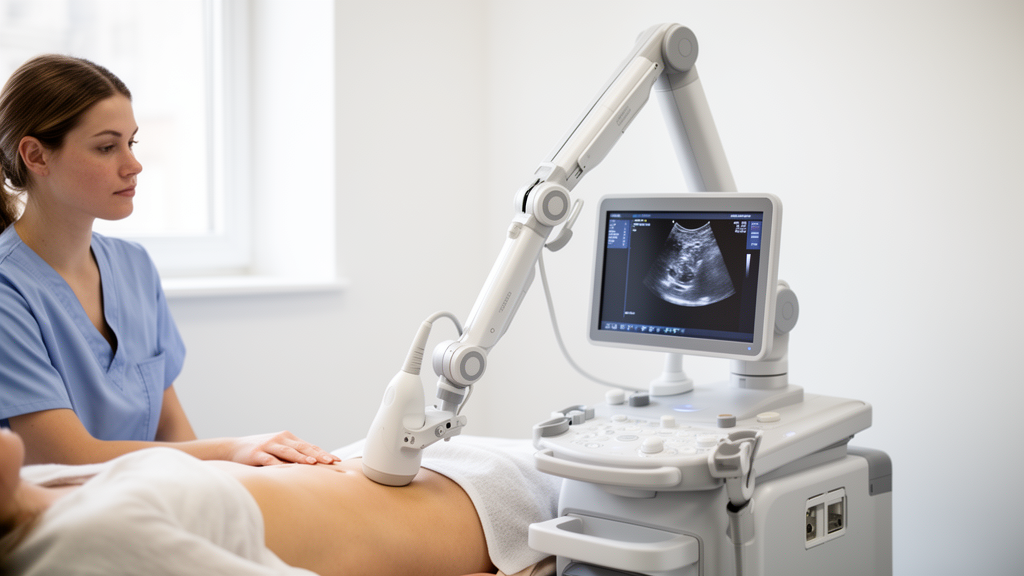
Researchers have developed a lightweight, portable ultrasound robot that can autonomously scan the liver, attaching directly to a patient’s abdomen and producing clinically interpretable images without a specialist holding the probe. The system is described in a study published in Nature Communications.
The robot’s key component is a decoupled end-effector weighing just 588 grams, controlled by an artificial intelligence agent trained on the trajectories of human sonographers. Because the device mounts on the body rather than standing beside it, it maintains stable contact force and controlled motion even while the patient breathes or when disturbances occur at the patient’s side, a persistent challenge for conventional robotic scanning setups.
The AI agent integrates spatial, tactile and visual feedback to navigate discontinuous acoustic windows, the limited passages through which ultrasound waves can reach the liver, and to acquire standard imaging planes despite anatomical variability and respiratory motion. These obstacles have previously limited autonomous ultrasound systems, which have also tended to rely on bulky hardware.
In evaluations involving 102 healthy participants and 17 patients, the system yielded clinically interpretable images, and the anatomical measurements it produced closely matched clinical references, according to the study.
The team also deployed the system for hepatic echinococcosis screening in a high-altitude, low-resource setting on the Qinghai-Tibet Plateau, and tested its performance in dynamic scenarios including scanning inside a moving vehicle. The researchers say the findings support portable, patient-mounted robotics for standardized ultrasound beyond specialist settings, potentially improving access to liver disease screening where trained sonographers are scarce.
Subject of Research: A lightweight portable robotic system for autonomous liver ultrasound scanning
Article Title: A lightweight portable ultrasound robot for autonomous liver sonography
Article References: Li, Z., Xu, Y., Zhang, L., Han, T., Yang, X., Wang, Y., Liu, M., Xin, S., Liu, L., Liao, H., & Ning, G. (2026). A lightweight portable ultrasound robot for autonomous liver sonography. Nature Communications. https://doi.org/10.1038/s41467-026-79007-5
Image Credits: AI Generated
DOI: 10.1038/s41467-026-79007-5
Keywords: ultrasound, robotics, liver, autonomous scanning, medical AI, portable devices, echinococcosis screening, Qinghai-Tibet Plateau, healthcare access, sonography, lightweight, portable
Cite Scienmag News
Denise Maddox. (October 29, 2026). Portable robot performs autonomous liver ultrasound scans. Scienmag. https://scienmag.com/portable-robot-performs-autonomous-liver-ultrasound-scans/
Denise Maddox. "Portable robot performs autonomous liver ultrasound scans." Scienmag, 29 October 2026, https://scienmag.com/portable-robot-performs-autonomous-liver-ultrasound-scans/. Accessed 29 October 2026.
Denise Maddox. "Portable robot performs autonomous liver ultrasound scans." Scienmag. October 29, 2026. https://scienmag.com/portable-robot-performs-autonomous-liver-ultrasound-scans/