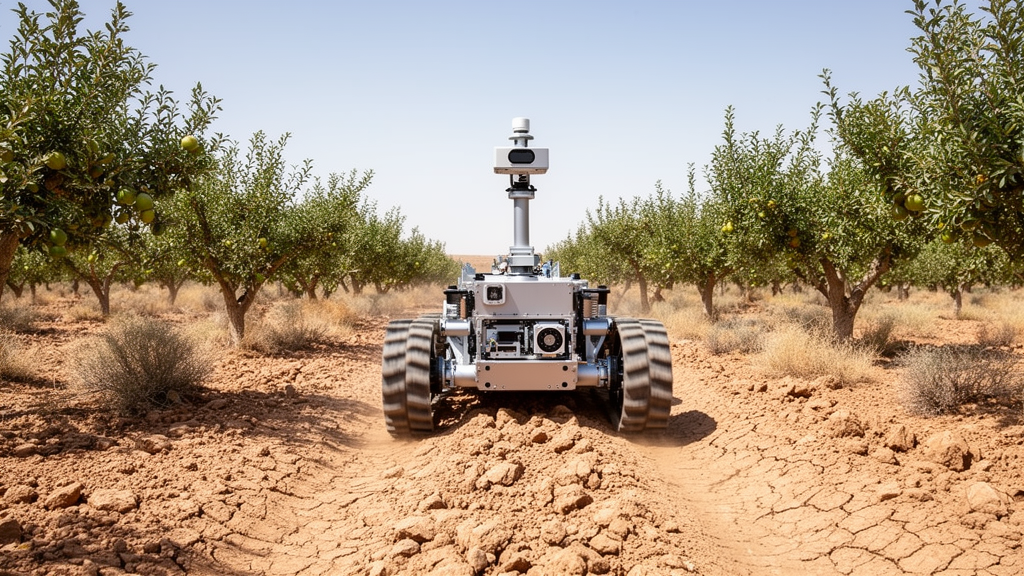
Agricultural roboticists from Xinjiang University and partner institutions have introduced an improved regional path planning algorithm tailored for autonomous mobile robots operating across the rugged and unstructured terrain of gobi orchards. Published in Frontiers in Robotics and AI, the research addresses the navigational hazards posed by unpaved gravel ground, irrigation furrows, and low-hanging branches from dwarf spindle-shaped fruit trees. To prevent robotic chassis from veering into ditches or snagging fruit-bearing limbs, the engineering team overhauled the traditional A* heuristic search method by integrating ditch-centerline distance penalty functions, a forward-facing semicircular arc search neighborhood, and a dynamically adjusted minimum turning radius circular arc smoothing routine. In standardized computational benchmarks, the improved method accelerated path planning speeds while significantly increasing lateral clearances from hazardous ditch edges.
Gobi orchards present an unforgiving operating environment for automated agricultural machinery, characterized by rocky gravel soil, narrow passages between planted rows, and deep irrigation furrows. Fruit tree row spacing of 2.5 meters and tree spacing constrain the lateral maneuvering space available to ground vehicles, while dwarf planting patterns cause branches to grow close to the ground, forming potential obstacles that may cause scraping or entanglement with the robot. Furthermore, the loose gravel surface induces intense mechanical vibrations in onboard vision systems during locomotion, complicating real-time localization. Irrigation ditches measuring one meter wide and half a meter deep run parallel to the tree rows, forming steep negative obstacles. Inadvertent deviations from the row centerline risk the robot approaching orchard ditches or causing scraping or entanglement with low-growing branches, demanding dependable trajectory generation.
Conventional path planning methods such as standard Dijkstra, greedy best-first search, and traditional A* algorithms struggle when deployed directly into these structured yet hazardous agricultural landscapes. The classical A* algorithm is a heuristic search algorithm that guides the search process using an evaluation function to reduce the search space, but it has limitations in path turning point planning, path smoothness, and computational efficiency, and does not consider safety distances from obstacle boundaries. Consequently, standard planners frequently produce trajectories that hug obstacle boundaries, cut tight corners across furrow edges, or execute abrupt heading changes that physical chassis cannot track. Jump point search integrated into the A* framework eliminates redundant nodes but is not applicable to non-uniform cost maps, whereas Theta* any-angle path planning does not consider the minimum turning radius. These operational bottlenecks necessitated an algorithm specifically tuned to orchard furrow geometry.
To structure the navigation challenge, the researchers established a two-level hierarchical planning framework that spans the global journey from orchard entrance to exit. At the upper level, an ordered waypoint generator maps out sequential passage through all orchard rows, fixing waypoints at the start and end of each row centerline and connecting adjacent rows through headland turning maneuvers. At the lower level, the proposed improved A* planner executes sequentially between each consecutive pair of waypoints to generate executable local trajectories. Rather than pursuing global optimality across the entire concatenated route, the lower-level planner optimizes individual transit segments under local cost formulations. The complete operating environment was modeled as a two-dimensional grid map with a cell resolution of zero point one meters, dividing the terrain into distinct functional zones.
The first major architectural modification modifies the core A* evaluation function by embedding regional traversal penalties and an orchard ditch distance constraint. The team segmented the grid environment into row-center passage areas, row-edge buffer zones, gravel hazard patches, and impassable ditch furrows. While travel through central passages incurs a baseline equivalent distance cost of one meter per meter traversed, travel within row-edge buffer zones is penalized with a steep regional cost coefficient of five meters per meter. Gravel patches receive an infinite risk cost, barring path generation across unstable ground. Furthermore, a ditch penalty term penalizes proximity to the furrow centerline, applying soft repulsive costs whenever the planner ventures within a predefined safety threshold, thus actively steering planned paths toward the safe center of the inter-row lane.
The second modification redesigns the node expansion mechanism to eliminate redundant evaluations in row-oriented field structures. Instead of exhaustively expanding an eight-neighborhood grid at every step, the planner implements a direction-constrained semicircular arc search strategy centered on the current node and oriented along the vehicle’s incoming travel direction. By restricting candidate successor nodes to a forward-facing semicircular envelope, the algorithm eliminates backward and perpendicular searches that run counter to row progression. Candidate diagonal steps undergo Bresenham line collision checks to prevent diagonal traversal through obstacle vertices. To maintain algorithmic completeness in trapped or heavily obstructed scenarios, the search state tracks quantized heading triplets, automatically falling back to an unconstrained eight-neighborhood expansion whenever the directional candidate set is empty or obstructed by physical obstacles.
The third modification applies a geometric smoothing pipeline to the raw polyline path generated by grid backtracking. Paths generated by the A* algorithm are typically composed of a series of discrete grid points and often contain numerous sharp turning angles that are not sufficiently smooth or safe for practical robot motion control. To generate smooth transitions, the algorithm identifies path corner points as control vertices and constructs circular arcs tangent to adjacent path segments based on the vehicle’s minimum turning radius. Using interior turning angles and chord geometries, the algorithm calculates continuous tangent circles and replaces discrete corners with smooth circular transitions. A dedicated collision detection module inspects the candidate arcs against obstacle boundaries, dynamically adjusting arc radii and tangent positions if conflicts arise. For segments where straight-line lengths cannot accommodate ideal arcs, local adjustments preserve safe execution without creating discontinuous kinks.
The researchers verified the individual contributions of each algorithmic component through systematic ablation experiments in MATLAB, executing each variant fifty times across a simulated Gobi orchard map. The baseline traditional A* planner generated paths averaging 951 meters with an average search time of 0.0247 seconds across 1,860 expanded nodes, yielding a minimum ditch edge clearance of only 0.1 meters. Introducing the ditch distance constraint increased clearance to 0.126 meters while lengthening the path to 1,040 meters. Implementing the semicircular arc expansion alone cut expanded nodes to 947 and search time to 0.0158 seconds. The fully integrated method combined a 0.0158-second search time and 0.0041-second smoothing time for an overall planning time of 0.0199 seconds, while increasing ditch clearance to 0.1527 meters and reducing maximum curvature from 14.142 to 10.000.
Comparative benchmarking against seven alternative path planning algorithms further confirmed the distinct operational profile of the improved planner. Evaluated against Dijkstra, greedy best-first search, traditional A*, jump point search, Theta*, adaptive-neighborhood A*, and ditch-distance exponential A*, the proposed method demonstrated superior execution speed and obstacle margins. Across randomized obstacle layouts with constant density, the improved planner reduced overall planning time by 19.43 percent and the number of searched nodes by 49.1 percent compared to traditional A*, while reducing the number of sharp turns by 69.7 percent from 33 turns down to 10 turns. Although the deliberate bias toward row centerlines increased total path length by 16.9 percent to 1,114 meters, it expanded minimum ditch clearance by 52.7 percent, trading nominal distance for vital collision safety.
To bridge theoretical formulation and practical implementation, the authors constructed a high-fidelity three-dimensional simulation environment in Gazebo and Robot Operating System Noetic. The virtual world mirrored physical orchard dimensions with continuous fruit tree rows, irregular ground stones, and one-meter furrows. Environmental mapping was evaluated using two-dimensional Cartographer SLAM, Hector SLAM, and GMapping fed by projected LiDAR scans. Cartographer achieved the highest global map consistency of 95.1 percent and completeness of 96.7 percent, avoiding the accumulated errors during long-term motion that affected Hector SLAM amid repetitive tree rows and the rapid divergence of the particle filter seen in GMapping over uneven terrain. Across five complete simulated orchard trials, the improved A* planner reduced trajectory planning times from 0.3722 seconds down to 0.2980 seconds—a 19.92 percent acceleration—while producing markedly smoother tracking paths.
Physical field validation was subsequently conducted using a tracked mobile chassis measuring 1,020 by 710 by 400 millimeters operating within a three-row forest stand configured with varying obstacle densities. Onboard environmental perception was handled by a Livox MID-360 three-dimensional LiDAR, whose point clouds were downsampled via voxel filtering, cleared of out-of-height canopy noise, and projected into horizontal scan messages for Cartographer mapping. Across fifteen experimental trials spanning low, medium, and high obstacle configurations, the improved A* planner consistently outperformed the conventional algorithm in computational efficiency. Planning times decreased by 12.97 percent in low-density tests, 14.20 percent in medium-density tests, and 14.16 percent under high density, while path length standard deviations remained tightly bounded between 0.1524 and 0.2520 meters, confirming exceptional repeatability under real-world sensor noise and rough ground conditions.
Despite these performance gains, the researchers highlighted several technical boundaries and open engineering challenges. Curvature analyses revealed that while path smoothing significantly lowered maximum curvature peaks, the proportion of sampled trajectory points exceeding strict turning limits slightly rose from 4.00 percent to 9.91 percent because cramped path segments forced dynamic arc adjustments. Furthermore, directional pruning and dynamic regional weighting mean that general completeness and mathematical global optimality cannot be claimed for unconstrained topologies. Current evaluations also focused on static environments, leaving dynamic obstacles unaddressed. Future development aims to combine this global regional planner with local collision avoidance frameworks such as the Dynamic Window Approach or reinforcement learning, improving autonomous decision-making in complex dynamic environments.
Subject of Research: Autonomous robotic path planning in complex gobi orchard environments using an improved A* algorithm
Article Title: A regional path planning method for gobi orchard furrows based on an improved A* algorithm
Article References: Liu, X., Hu, G., Zou, X., Jiang, H., Wu, F., & Tan, C. (2026). A regional path planning method for gobi orchard furrows based on an improved A* algorithm. Frontiers in Robotics and AI, 13, Article 1972321. https://doi.org/10.3389/frobt.2026.1972321
Image Credits: AI Generated
DOI: 10.3389/frobt.2026.1972321
Keywords: agricultural robotics, path planning, A* algorithm, gobi orchards, autonomous navigation, mobile robots, field robotics, obstacle avoidance, regional, path, planning, method
Cite Scienmag News
Denise Maddox. (November 10, 2026). Improved Path Planning Algorithm Guides Autonomous Robots Through Rugged Gobi Orchards. Scienmag. https://scienmag.com/improved-path-planning-algorithm-guides-autonomous-robots-through-rugged-gobi-orchards/
Denise Maddox. "Improved Path Planning Algorithm Guides Autonomous Robots Through Rugged Gobi Orchards." Scienmag, 10 November 2026, https://scienmag.com/improved-path-planning-algorithm-guides-autonomous-robots-through-rugged-gobi-orchards/. Accessed 10 November 2026.
Denise Maddox. "Improved Path Planning Algorithm Guides Autonomous Robots Through Rugged Gobi Orchards." Scienmag. November 10, 2026. https://scienmag.com/improved-path-planning-algorithm-guides-autonomous-robots-through-rugged-gobi-orchards/