

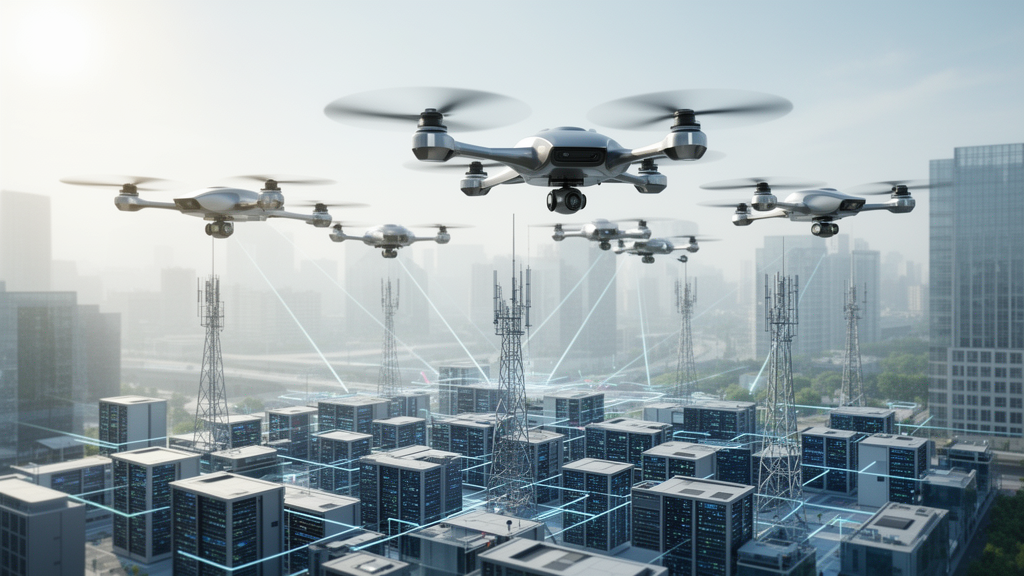
A newly proposed federated reinforcement learning algorithm jointly optimizes computational task offloading decisions and aerial flight trajectories in multi-unmanned aerial vehicle mobile edge computing networks. Known as FRLJTO, the framework was engineered to coordinate offloading choices alongside trajectory control to overcome persistent operational bottlenecks in aerial edge computing environments. In simulated evaluations, the joint optimization approach demonstrated clear operational advantages by reducing average access delay, decreasing total system energy consumption, lowering weighted total cost, and improving effective network throughput relative to existing baseline algorithms.
The investigation focuses on overcoming significant operational challenges identified in existing multi-agent reinforcement learning methods utilized within mobile edge computing. While conventional multi-agent reinforcement learning approaches can successfully handle high-dimensional dynamic optimization problems, they exhibit critical shortcomings when deployed in multi-UAV-assisted networks. Specifically, these established algorithms suffer from frequent parameter interactions, severe communication overhead, and insufficient coordination between task offloading decisions and physical trajectory control across the cooperating aerial nodes.
To resolve these coordination deficits, the research models a structured two-hop offloading scenario that accounts for key technical and operational parameters. Within this framework, task uploading from local devices, cooperative relaying performed by intermediate unmanned aerial vehicles, edge computing execution, and explicit flight constraints are jointly modeled into a unified formulation. Under the primary operational objective of minimizing overall system delay and total energy consumption, the algorithm jointly optimizes the offloading ratio, target node selection, and UAV trajectory control.
For local decision-making on individual unmanned aerial vehicles, the researchers developed a specialized control method based on prioritized experience replay twin delayed deep deterministic policy gradient, abbreviated as PER-TD3. Furthermore, model predictive control is incorporated into the architecture to perform rolling corrections on trajectory sub-actions during execution. The introduction of model predictive control specifically targets trajectory behavior, thereby improving both the smoothness and the physical feasibility of trajectory control for the aerial vehicles in flight.
To facilitate effective multi-UAV coordination while preventing prohibitive communication burdens, the proposed system introduces a federated policy-sharing mechanism. Instead of synchronizing entire model structures across the fleet, the federated mechanism aggregates only the main Actor parameters. This selective parameter sharing is supported by parameter compression, semi-synchronous updating, and quality-aware weighting strategies, which together maintain policy coordination among multiple unmanned aerial vehicles while substantially reducing additional parameter synchronization overhead across the wireless channels.
Simulation results confirmed the effectiveness of the proposed FRLJTO algorithm in multi-UAV-assisted mobile edge computing scenarios when benchmarked against several existing methods. Specifically, the framework was evaluated in direct comparison with baseline algorithms including Meta-MASAC, AF-MAAC, MUCOO, and DGTT. Across these comparative simulation experiments, the FRLJTO algorithm effectively reduced average access delay, decreased system energy consumption, and minimized weighted total cost, while simultaneously achieving notable improvements in effective throughput within the mobile edge computing network.
By coupling local deep reinforcement learning with model predictive control and parameter-compressed federated policy sharing, the research presents an integrated approach to aerial edge computing management. The unified framework demonstrates how simultaneous optimization of offloading ratios, relay node selection, and flight paths can alleviate the communication bottlenecks and parameter synchronization burdens typically associated with multi-agent aerial networks.
Subject of Research: Multi-UAV mobile edge computing optimization
Article Title: Federated reinforcement learning for joint task offloading and trajectory optimization in multi-UAV-assisted MEC
Article References: Liu, Y., Liu, K., Shi, X., Wang, H., Gan, C., & Cui, Y. (2026). Federated reinforcement learning for joint task offloading and trajectory optimization in multi-UAV-assisted MEC. Cluster Computing, 29(16), Article 915. https://doi.org/10.1007/s10586-026-06644-2
Image Credits: AI Generated
DOI: 10.1007/s10586-026-06644-2
Keywords: federated reinforcement learning, mobile edge computing, unmanned aerial vehicles, trajectory optimization, task offloading, model predictive control, PER-TD3, parameter compression, Federated, reinforcement, learning, joint
Cite Scienmag News
Marilyn Langley. (November 10, 2026). Federated Reinforcement Learning Optimizes Multi-UAV Mobile Edge Computing. Scienmag. https://scienmag.com/federated-reinforcement-learning-optimizes-multi-uav-mobile-edge-computing/
Marilyn Langley. "Federated Reinforcement Learning Optimizes Multi-UAV Mobile Edge Computing." Scienmag, 10 November 2026, https://scienmag.com/federated-reinforcement-learning-optimizes-multi-uav-mobile-edge-computing/. Accessed 10 November 2026.
Marilyn Langley. "Federated Reinforcement Learning Optimizes Multi-UAV Mobile Edge Computing." Scienmag. November 10, 2026. https://scienmag.com/federated-reinforcement-learning-optimizes-multi-uav-mobile-edge-computing/




