

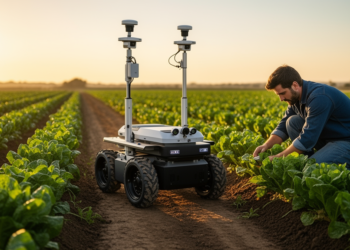
Robots on the farm: what it takes to make autonomous agriculture trustworthy
A new review argues that trustworthy agricultural autonomy depends on integrating robot learning, safe control and human-robot interaction rather than ...
A new review argues that trustworthy agricultural autonomy depends on integrating robot learning, safe control and human-robot interaction rather than ...
A low-cost wrist wearable running an optimized random forest model on-device detected simulated convulsive and non-convulsive seizures with high sensitivity ...
A simulation study presents an ISO 26262-inspired multi-layer safety architecture for powered two-wheelers that achieved 88 percent collision detection and ...
Researchers introduced a dual-robust unscented Kalman filter, H∞-GMMC-UKF, which significantly improved UAV state estimation accuracy by addressing simultaneous model mismatch ...
A new research collection spanning tactile arrays, sim-to-real tactile learning, LiDAR-camera calibration, structured visual reasoning and virtual social touch shows ...
Researchers in Türkiye have combined IoT sensors, gradient-boosted machine learning, and a safely grounded large language model into a prototype ...
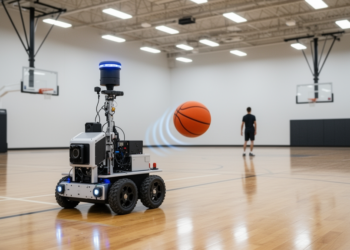
A YOLOv5-LiDAR basketball-robot system achieved 97.85% detection accuracy and high task-success rates in controlled dataset evaluations and simulations, with extreme ...
A new review maps how advances in computer vision, vision language models and reinforcement learning could enable collaborative robots to ...
Researchers have built an AI-powered traffic control system that uses cameras, infrared and sound sensors with lightweight neural networks to ...
Researchers at the University of the Punjab have introduced HumCareADL, a demographically diverse multimodal wearable dataset, and HyMCL-Net, a hybrid ...


Embark on a thrilling journey of discovery with Scienmag.com—your ultimate source for cutting-edge breakthroughs. Immerse yourself in a world where curiosity knows no limits and tomorrow’s possibilities become today’s reality!