


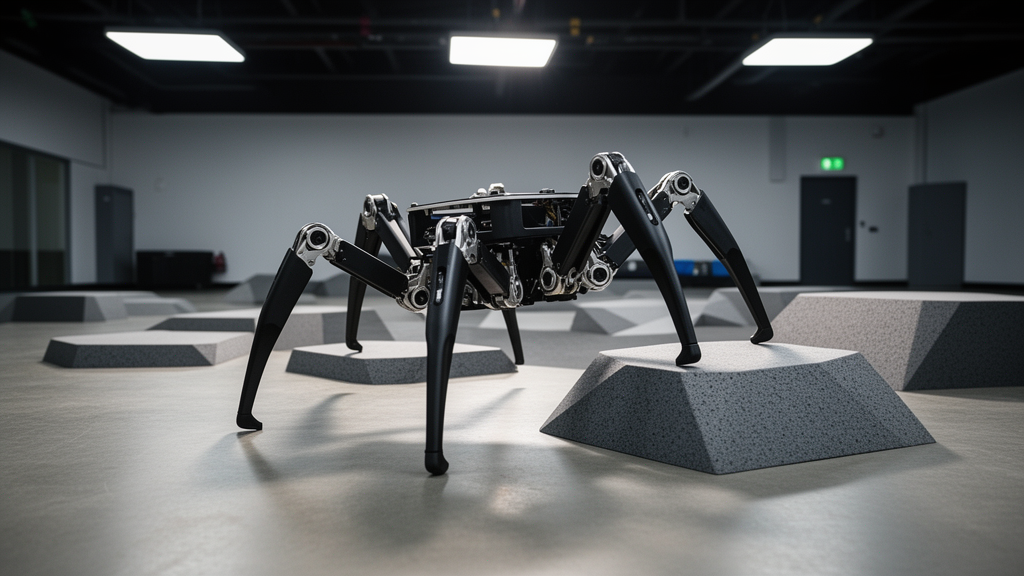
A theoretical and computational framework published in Frontiers in Neurorobotics by Alexander D. Shaw investigates how embodied artificial agents can coordinate complex movement across multiple limbs without relying on a centralized command node. In natural environments, physical movement continuously alters an agent’s load distribution, surface contact, and capacity for future action, making the physical body an active participant in computation rather than a passive actuator executing global instructions. Shaw proposes organizing robotic cognition through distributed, hierarchical, and plural active inference processes, formalizing an operational concept termed coordination without command. Rather than deploying an overarching master controller that computes and broadcasts complete joint trajectories or fixed footfall schedules across the entire system, the architecture delegates state estimation and policy selection to semi-autonomous, leg-local predictive controllers. These local units resolve immediate sensorimotor uncertainties at their respective physical interfaces while remaining functionally synchronized through bounded neighbor-to-neighbor messaging, shared contextual constraints, and the mechanical feedback inherently transmitted through the shared physical chassis.
Embodied intelligence presents unique computational bottlenecks for traditional robotic frameworks that structure control around monolithic decision centers. In conventional reinforcement learning and centralized control architectures, a single optimizer must gather body-wide sensory streams, compute multi-joint state estimates, and dictate synchronous actions across all degrees of freedom in real time. As bodies increase in mechanical complexity, compliance, and contact dimensions, this centralized approach suffers from the curse of dimensionality. The operational challenge is compounded because an agent’s bodily configuration, structural compliance, contact forces, and actuator health are never fully known in advance and are continuously reshaped by the agent’s own actions. Shaw formalizes this dynamic by treating the body itself as an uncertain state within a generative model, where environmental hidden causes, bodily states, and task preferences interact continuously. Changes in an individual limb’s force production immediately redistribute loads across the chassis, altering the physical evidence encountered by neighboring limbs and establishing mechanics as both a medium of physical coupling and an object of local perceptual estimation.
Active inference resolves these multi-scale challenges by unifying perception, learning, and action selection within a single formal objective: the minimization of variational free energy. Under this formulation, perception corresponds to updating an approximate posterior belief over hidden environmental and bodily states to reduce discrepancy between expected and encountered sensory inputs, while action serves to sample the world in ways that fulfill prior setpoints. For prospective action selection, the framework evaluates potential policies using expected free energy, which naturally integrates goal-directed utility with epistemic value, directing agents toward movements that simultaneously achieve operational preferences and reduce future sensory ambiguity. While active inference has frequently been implemented in centralized systems that collapse all uncertainty into a single global posterior before taking action, Shaw argues that its underlying mathematical structure does not require monolithic execution. Instead, the framework can be mathematically factorized across distributed message-passing networks, allowing localized generative models to operate near the sensory boundary while preserving formal coherence across the entire embodied system.
To articulate the architecture of coordination without command, the study establishes three complementary organizational dimensions: distributed inference, hierarchical inference, and plural inference. Distributed inference defines the physical and computational location where beliefs are maintained and updated, ensuring that distinct peripheral nodes process non-identical sensory streams without funneling every local observation into an overarching computational bottleneck. Hierarchical inference organizes predictive processing across distinct spatial and temporal horizons, where slower, higher-level processes infer broad behavioral contexts and modulate operational constraints, while faster, lower-level loops address immediate, high-frequency contact dynamics without requiring step-by-step central oversight. Plural inference ensures that separate local posteriors retain genuine authority over their respective physical action channels following lateral communication, rather than being subordinated to an integrated global action selector. In this plural paradigm, individual controllers maintain distinct policy distributions and execute local maximum a posteriori selections, preserving responsive local autonomy even when system-wide coordination variables remain partially heterogeneous or subject to unresolved local uncertainties.
The theoretical motivation for this distributed architecture draws substantial inspiration from biological systems, most notably the octopus. The octopus exhibits extreme sensorimotor decentralization, housing a large proportion of its nervous system within peripheral arm circuits that autonomously govern local grasping, elongation, twisting, and tactile exploration without requiring continuous central micromanagement. The central brain establishes broad behavioral directives—such as hunting, navigating, or escaping—while peripheral neuromuscular networks resolve complex, high-dimensional mechanical deformations through hierarchical bounded autonomy. Shaw notes that distributed physical coordination extends beyond nervous systems, pointing to long-distance calcium signaling networks that orchestrate systemic defenses in plants and structural stress transmission across mycelial networks in fungi.
To ground these theoretical concepts in a concrete computational benchmark, Shaw developed an articulated hexapod simulation within the PyBullet physics engine, encompassing 18 degrees of freedom distributed across six identical three-joint limbs. The simulation explicitly dissociates temporal rates, integrating physical dynamics at 240 Hz while running inference, lateral messaging, and policy selection at a lower frequency of 20 Hz. Each leg functions as an autonomous predictive control loop receiving a local observation vector comprising ground contact state, normalized limb load, absolute femur-angle deviation from a stance reference, and a normalized femur angular-speed proxy. From this feedback, each leg’s local generative model computes three gradient descent updates per 20-Hz tick to update a four-dimensional posterior state estimating support contribution, foothold quality, limb availability, and expected load. Controllers evaluate candidate operational modes—stance, swing, and recover—over a two-step discrete planning horizon, scoring each trajectory using an expected-free-energy formulation balanced with engineered penalties for phase error, neighbor coordination, stability margins, and load redistribution.
Lateral coordination among the hexapod’s six predictive controllers occurs through an engineered messaging topology without any central arbiter dictating gaits. Under intact operating conditions, the communication network consists of two ipsilateral chains interconnected by three contralateral edges across the chassis. Neighboring limbs exchange their current phase, prior policy distributions, and coordination reliability metrics, while participating in synchronized consensus routines to arbitrate stance and swing transitions. Support consensus algorithms track active module membership and evaluate chassis stability before permitting limb lifts, while a localized max-consensus routine grants swing permissions based on accumulated waiting time, angular tracking error, and phase urgency, while strictly penalizing lifts under heavy physical loads.
The intact system achieved a mean forward velocity of 0.0730 meters per second and an absolute net displacement of 0.7537 meters on flat terrain. Mechanical stability remained high throughout the trial, exhibiting a mean physical support count of 3.169 contacting feet, with the robot sustaining at least three grounded limbs in 96.5 percent of all sampled time steps and maintaining a low average support deficit of 0.012.
To evaluate system resilience under structural trauma, Shaw subjected the hexapod to an impairment trial wherein the left-middle leg was abruptly withdrawn at controller time t = 8 seconds. The disruption was induced via an explicit failure signature that set the limb’s local observations to an error vector, clamped its health estimate to zero, retracted the leg, and triggered a programmed topological reconfiguration that rewired the remaining five controllers into an anatomical ring with modified winding-sector phase priors. Following reconfiguration, the remaining five limbs sustained continuous stepping, producing a post-loss forward velocity of 0.0384 meters per second and a net displacement of 0.4011 meters with 92.6 percent phase-action agreement. However, critical stability metrics deteriorated: the post-loss support deficit rose to 0.101, exceeding the target threshold of less than 0.10, while late root-mean-square winding-aware phase error reached 0.0654, surpassing the acceptable ceiling of 0.05. Consequently, the study emphasizes that the hexapod achieved retained mechanical movement via preprogrammed graph rewiring rather than demonstrating sustained inferential remapping or autonomous functional recovery.
The study contextualizes these findings by evaluating design trade-offs against a 20-seed, 30-second reduced-order benchmark comparing centralized tripod clocks, independent local controllers, coupled local controllers, and coupled-plural controllers. In this abstract model, the centralized tripod controller achieved the highest distance (5.603 ± 0.000) and post-loss speed (0.159), whereas independent controllers suffered severe performance collapse (1.257 ± 0.000 distance, 0.544 stability). The coupled local and coupled plural controllers exhibited intermediate forward progress (4.559 ± 0.007 and 4.556 ± 0.007, respectively) alongside superior stability metrics (0.975), with plural conditions demonstrating higher policy entropy (0.292 versus 0.033). Shaw underscores several experimental boundaries: the simulation ran synchronously within a single process, leaving physical hardware transfer, communication latencies, and rough-terrain adaptability unexamined. Furthermore, because intact locomotion combined local inference, mechanical compliance, and hand-tuned coordination heuristics, these tests demonstrate the feasibility of distributed active inference in legged bodies without proving that local probabilistic inference is strictly necessary or universally superior to traditional centralized engineering designs.
Subject of Research: Distributed active inference and decentralized control architecture in embodied robotics
Article Title: Coordination without command: active inference and the route to embodied intelligence
Article References: Shaw, A. D. (2026). Coordination without command: active inference and the route to embodied intelligence. Frontiers in Neurorobotics, 20, 1898490. https://doi.org/10.3389/fnbot.2026.1898490
Image Credits: AI Generated
DOI: 10.3389/fnbot.2026.1898490
Keywords: active inference, embodied intelligence, distributed control, hexapod robotics, hierarchical inference, plural inference, predictive processing, morphological computation, variational free energy, expected free energy, locomotion control, biological robotics, sensorimotor loop, consensus arbitration, robotic simulation, PyBullet mechanics
Cite Scienmag News
Denise Maddox. (November 12, 2026). Hexapod Simulation Explores Distributed Active Inference for Robot Locomotion Without Central Control. Scienmag. https://scienmag.com/hexapod-simulation-explores-distributed-active-inference-for-robot-locomotion-without-central-control/
Denise Maddox. "Hexapod Simulation Explores Distributed Active Inference for Robot Locomotion Without Central Control." Scienmag, 12 November 2026, https://scienmag.com/hexapod-simulation-explores-distributed-active-inference-for-robot-locomotion-without-central-control/. Accessed 18 November 2026.
Denise Maddox. "Hexapod Simulation Explores Distributed Active Inference for Robot Locomotion Without Central Control." Scienmag. November 12, 2026. https://scienmag.com/hexapod-simulation-explores-distributed-active-inference-for-robot-locomotion-without-central-control/




