

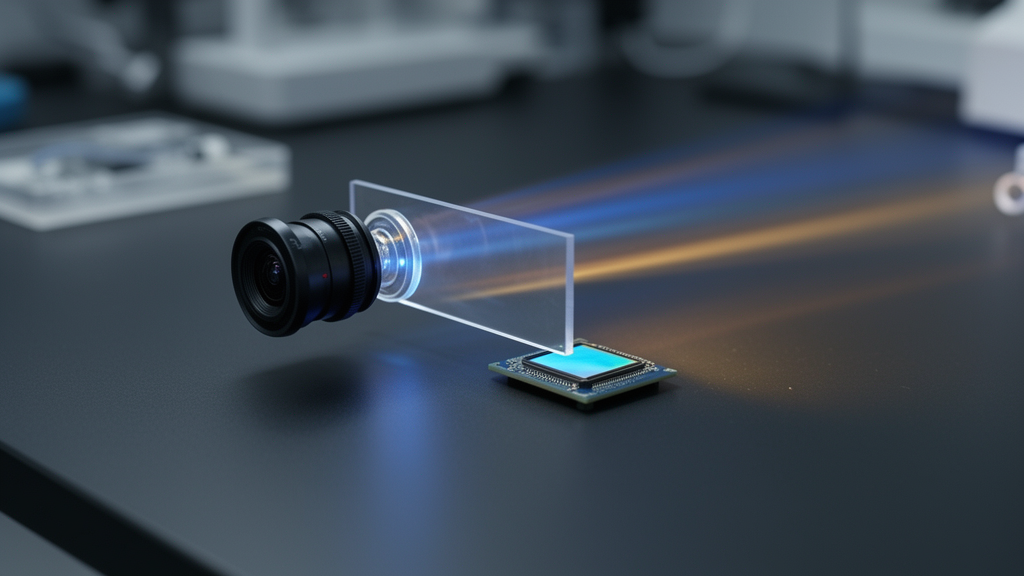
A team of researchers at Tsinghua University has published a comprehensive review of an emerging discipline that could fundamentally reshape how machines see the world: optical pre-sensor computing. The review, titled Review of Optical Pre-sensor Computing and published in a peer-reviewed journal of the Chinese Society for Optical Engineering, examines a deceptively simple but profound idea. Instead of waiting until light has been converted into digital pixels and shipped off to an electronic processor, why not let the optics itself perform useful computation while the light is still in flight? By embedding mathematical operations into the propagation of light before photodetection, the approach promises to strip away enormous amounts of redundant visual data at the very first stage of the machine vision pipeline, easing bandwidth demands, cutting latency and lowering the energy cost of perception for robots, autonomous vehicles and other physical AI systems.
To understand why this matters, it helps to consider how conventional machine vision actually works. A typical pipeline consists of separate, serially connected stages: a lens forms an image, an image sensor digitizes it, the raw data are transmitted over a bus or network, and an electronic processor finally extracts meaning from the numbers. Every stage in that chain carries the full weight of the previous one. A high-resolution camera may generate megabytes of data per frame, yet the downstream task, whether recognizing a pedestrian or grasping an object, may need only a tiny fraction of that information. Digitizing and moving all those raw pixels consumes energy and time at every step, and the burden grows precisely where it is least affordable: on robots and autonomous platforms that must perceive a changing environment while operating under tight power, thermal and space constraints.
Optical pre-sensor computing attacks this bottleneck at its origin. The central insight is that light traveling through a well-designed optical system is already performing mathematics for free. When wavefronts diffract, interfere, scatter or pass through engineered elements, the resulting intensity pattern at the sensor plane can correspond to a convolution, a correlation, a Fourier transform or a derivative of the input scene. In other words, the optical front end can extract task-relevant features or compress visual information before the sensor ever captures an image. The sensor then records not the raw scene but a pre-processed, information-rich representation, dramatically reducing redundant data acquisition and the subsequent electronic processing load. The review surveys these elementary optical operations in detail, including convolution and differentiation, and traces how they can be composed into more powerful computational primitives.
Building on these primitives, researchers have constructed optical neural networks, architectures that map the layers of an artificial neural network onto physical light propagation. The review categorizes several distinct design families. Diffractive optical neural networks stack patterned layers that sculpt the phase of passing wavefronts, so that a network’s weights are physically encoded in the layer geometry. Fourier-optics schemes exploit the natural ability of a lens to perform the optical Fourier transform, enabling convolutions to be executed as simple pointwise multiplications in the frequency domain. Other architectures draw on scattering media and geometrical optics, and some designs are directly integrated with image sensors, blurring the boundary between optics and detector. Each family trades off fabrication complexity, alignment tolerance and computational expressiveness, and the review systematically maps this design space for readers evaluating the technology’s maturity.
One of the review’s central technical themes is nonlinearity. Linear optical systems, however elaborate, can only perform linear transformations on the input light, and deep neural networks derive much of their power from nonlinear activation functions inserted between layers. Extending optical neural networks beyond linear operations therefore requires nonlinear activation mechanisms, and the authors devote careful attention to this challenge. They compare optoelectronic approaches, in which light is converted, modulated and re-emitted to introduce nonlinearity, with all-optical mechanisms that seek nonlinearity within the optical domain itself. The comparison is framed around practical trade-offs in response speed, illumination requirements and power consumption, the very parameters that determine whether a given nonlinear scheme can support real-world visual processing rather than a laboratory demonstration.
The review then turns to the requirements that matter for deployment in physical AI, the class of embodied systems, from industrial robots to autonomous platforms, that must sense and act in the physical world. Three requirements stand out. First, compact integration: bulky free-space optical benches are incompatible with a robot’s head or a vehicle’s sensor suite, so optical front ends must be miniaturized, potentially using metasurfaces and photonic integration. Second, compatibility with real-world incoherent light: many laboratory demonstrations rely on coherent laser illumination, but natural scenes are lit by incoherent, broadband light, and practical pre-sensor systems must work under such conditions. Third, low-power reconfigurability: a fixed optical function is of limited use when tasks change, so the computational function of the optical front end should be tunable to match the target task. Active modulators provide this flexibility, but the authors caution that their power demands must be counted honestly when assessing overall system efficiency, since an energy-hungry modulator could erase the savings the optical front end delivers.
Robustness adds a further layer of engineering difficulty. Optical front ends mounted on moving platforms must withstand motion, vibration and environmental change without losing their calibrated computational function, and their operations should be matched to the specific perceptual tasks the system must perform. A pre-sensor design optimized for one visual task may be poorly suited to another, which makes co-design between the optical front end and the downstream task a central theme. The review’s treatment of these constraints is notably candid: rather than presenting optical pre-sensor computing as a finished technology, it frames the field as a set of promising building blocks whose practical value depends on solving integration, stability and power problems that are well defined but far from trivial.
Perhaps the most forward-looking portion of the review concerns how pre-sensor computing could connect to the rest of the computational stack. The authors discuss combining optical processing before the sensor with computation within and near the sensor itself, and with integrated photonic computing chips that can carry out deeper inference on the optical front end’s output. In such a coordinated perception pipeline, light would be progressively transformed and compressed at every stage: features extracted in free space or on-chip optics, further processed in sensor-adjacent circuitry, and finally interpreted by photonic or electronic neural processors. This vision of an end-to-end optical-electronic inference chain is compelling, but the authors are clear about the obstacles. Coupling losses between optical stages, the need for compatible signal representations across the optical-electronic boundary, and the challenge of jointly training heterogeneous optical and electronic components all remain open problems that the community must solve before such pipelines become routine.
Taken together, the review positions optical pre-sensor computing as a potential visual foundation for physical AI, a way of delivering the perceptual information that subsequent planning and action modules need, at a fraction of the data movement and energy cost of conventional pipelines. The significance extends beyond any single application. As machines are asked to perceive faster, richer and more power-constrained environments, from autonomous vehicles navigating cluttered streets to drones inspecting infrastructure, the traditional separation between imaging and computing becomes an increasingly expensive artifact of history. The Tsinghua team’s synthesis suggests that the boundary is now negotiable, and that some of the earliest, cheapest and most parallel computation available to a machine may be the computation that light performs on its own way to the sensor. For a field racing to give physical AI systems fast, frugal and reliable eyes, that is a proposition worth watching closely.
Subject of Research: Optical pre-sensor computing for efficient machine vision in physical AI
Article Title: Optical pre-sensor computing opens new possibilities for efficient vision in physical AI
Article References: Optical pre-sensor computing opens new possibilities for efficient vision in physical AI. (n.d.). Original publication
Image Credits: AI Generated
DOI: Not provided
Keywords: optical pre-sensor computing, optical neural networks, machine vision, physical AI, diffractive optics, Fourier optics, nonlinear activation, image sensors, photonic computing, low-power perception, robotics, Tsinghua University
Cite Scienmag News
Bethany Barker. (October 16, 2026). Computing with Light Before the Sensor: A New Vision Pipeline for Physical AI. Scienmag. https://scienmag.com/computing-with-light-before-the-sensor-a-new-vision-pipeline-for-physical-ai/
Bethany Barker. "Computing with Light Before the Sensor: A New Vision Pipeline for Physical AI." Scienmag, 16 October 2026, https://scienmag.com/computing-with-light-before-the-sensor-a-new-vision-pipeline-for-physical-ai/. Accessed 16 October 2026.
Bethany Barker. "Computing with Light Before the Sensor: A New Vision Pipeline for Physical AI." Scienmag. October 16, 2026. https://scienmag.com/computing-with-light-before-the-sensor-a-new-vision-pipeline-for-physical-ai/


