

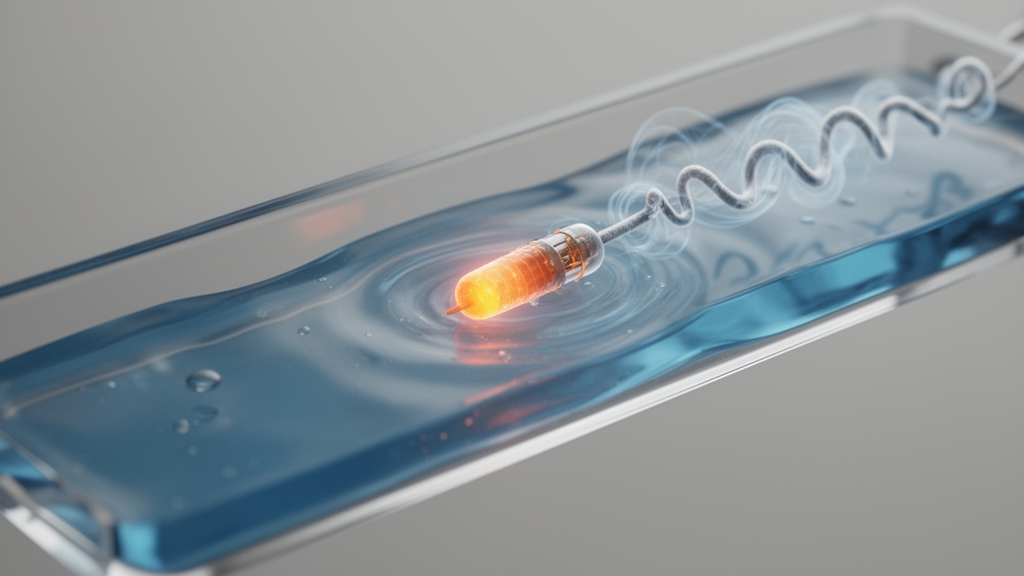
The achievement reported by the Cornell team sits at the intersection of several long-standing engineering challenges: miniaturization, actuation, sensing, and collective behavior. At scales below a millimeter, the physics of the world changes dramatically. Viscous forces dominate over inertia, meaning that a microscopic robot cannot simply flap a limb back and forth and expect to propel fluid, because reciprocal motion produces no net flow at low Reynolds numbers. This constraint, often illustrated by the observation that a scallop opening and closing its single hinge would merely oscillate in place in viscous fluid, is precisely why the researchers’ two-hinge design matters. By breaking the symmetry of motion—moving one hinge and then the other in a deliberate sequence—the artificial cilia generate a nonreciprocal stroke that imparts directional momentum to the surrounding liquid, a strategy that microscopic organisms such as paramecia and the cells lining human airways have exploited for hundreds of millions of years.
Natural cilia offer a compelling blueprint because they accomplish something remarkable for structures only a few micrometers long: they move fluid efficiently and in coordinated waves. In the human respiratory tract, for example, hundreds of cilia on each epithelial cell beat in metachronal waves to sweep mucus and trapped pathogens upward. Replicating this at the microscale with conventional motors has proven impractical, since electromagnetic motors cannot easily be shrunk below tens of micrometers while retaining useful power. The Cornell team’s solution relies on actuators and electronics fabricated using semiconductor manufacturing techniques, which allows the cilia to be addressed individually or in groups by electronic signals. This programmability is what distinguishes the new work from earlier microfluidic pumping schemes that relied on passive structures or externally applied fields.
The choice of temperature as the sensed variable is scientifically significant for several reasons. Temperature gradients are ubiquitous in both natural and engineered microenvironments, and they influence diffusion rates, chemical reaction kinetics, fluid density and therefore convection, and the viability of living cells. In a biomedical context, localized temperature differences can signal inflammation, infection, or the presence of tumors, which often run slightly warmer than surrounding tissue due to elevated metabolic activity. A swarm of microrobots capable of detecting such gradients and actively redistributing heat—or the dissolved and suspended contents of the fluid they move—could in principle perform corrective actions at sites that conventional catheters and externally applied fields reach only crudely. The feedback loop demonstrated here, in which sensing drives actuation and actuation changes the very quantity being sensed, is the minimal architecture of what control engineers call closed-loop regulation, implemented for the first time among cooperating microscopic machines.
The leader-follower communication scheme deserves particular attention. Coordinating even two independent microchips requires a protocol that is robust to noise, timing jitter, and the power constraints inherent to sub-millimeter electronics. The two temperature-sensing circuits described in the release function as a distributed decision-making system: the leader detects the thermal state of the environment and the follower adjusts its pumping behavior accordingly, with the cilia array serving as the shared actuator. This division of labor mirrors strategies found in biological collectives, where individual cells or organisms respond to local cues and to signals from neighbors rather than to any central controller. Scaling such schemes to larger numbers of robots raises questions about synchronization stability, communication bandwidth, and fault tolerance, all of which are active areas of research in swarm robotics and distributed computing.
The pumping direction logic described by Cohen—forward flow above a threshold temperature, reverse flow below it—constitutes a simple but powerful control policy. It effectively turns the cilia array into a microscopic thermostat that can either concentrate warm fluid where it is needed or flush it away where it is not. Because the cilia are electronically programmable, the threshold, stroke sequence, and pumping rate can in principle be reconfigured without physically altering the hardware. This flexibility matters for real-world deployment, where the desired behavior may depend on the application: in agriculture, for instance, one might want to circulate nutrient solution around plant roots or leaf surfaces, while in medicine the goal might be to modulate the thermal environment of a wound or a surgical site.
The scale of the robots—described as roughly the width of a human hair—places them in a regime where surface forces overwhelm body forces. Capillary adhesion, electrostatic attraction, and viscous drag all become dominant, while gravity becomes nearly irrelevant. Fabricating machines that operate reliably under these conditions requires not only miniaturized actuators but also onboard electronics that can sense, compute, and communicate while drawing minuscule amounts of power. The Cornell group’s earlier demonstrations of autonomous walking robots, environmental sensors, imaging capabilities, and inter-robot communication each addressed a piece of this puzzle. The current work integrates those pieces into a single functional system, which is arguably the more difficult engineering feat: any one capability can be demonstrated in isolation, but combining them without interference demands careful co-design of mechanics, electronics, and control software.
The prospect of future iterations responding to light or pH, as Cohen suggests, opens a broad design space. Light is attractive as a stimulus because it can be delivered remotely, patterned spatially, and modulated in intensity and wavelength, allowing external operators or onboard logic to trigger specific behaviors. pH sensing would be valuable in biological contexts, since acidity varies across tissues and organelles and shifts in disease states such as tumors or infected wounds. Coupling chemical sensing to mechanical actuation—setting off reactions or motions in response to molecular cues—would move these systems closer to the kind of chemotactic behavior seen in bacteria, which swim toward nutrients and away from toxins by comparing concentrations over time. A swarm of programmable microrobots performing analogous logic, but with engineered responses, would represent a substantial advance toward active matter systems that intervene in their chemical as well as physical environments.
The idea of robots that walk independently rather than remaining fixed in an array introduces additional challenges and opportunities. A mobile microrobot must contend with locomotion efficiency at low Reynolds number, where drag dominates and momentum cannot be stored; the walking robots developed previously by the Cohen lab address this with coordinated leg-like actuation. Mobility would allow robots to seek out regions of interest rather than waiting for the environment to come to them, and it would enable dynamic reconfiguration of the collective, with robots aggregating where sensing indicates action is needed and dispersing when it does not. Combining mobility with the pumping and sensing capabilities demonstrated here would yield a system capable of both locating and reshaping thermal or chemical gradients, a level of autonomy that no current microrobotic platform fully achieves.
Publication in Nature Electronics situates the work within a growing literature on micro- and nanorobotics that has accelerated over the past decade, driven by advances in semiconductor fabrication, new actuator materials, and improved understanding of low-Reynolds-number hydrodynamics. The field draws inspiration from biological microswimmers—sperm cells, bacteria, ciliated protozoa—whose propulsion strategies have been analyzed mathematically since the 1950s and 1970s in the work of researchers such as Edward Purcell and George Oster. Translating those insights into engineered devices required waiting for manufacturing technology to catch up, and the Cornell team’s use of standard microfabrication suggests a path toward mass production, which is essential if such robots are ever to be deployed in the large numbers needed for practical applications. A single robot, however capable, cannot meaningfully alter the temperature of even a small volume of fluid; thousands or millions working in concert, as the 54-cilia array foreshadows, are required to achieve macroscopic effect from microscopic action.
The phrase Cohen uses—little things can have a large impact—captures the central promise and the central difficulty of microrobotics. The promise is that swarms of tiny machines, each individually simple, can accomplish tasks that no single large machine could: navigating tortuous biological channels, operating inside sealed microfluidic systems, or distributing interventions with cellular precision. The difficulty is that every function—power, sensing, computation, communication, actuation—must be rebuilt from scratch at a scale where conventional engineering intuition often fails. The Cornell demonstration, by showing sensing, communication, and coordinated actuation operating together in a closed loop for the first time, marks a milestone in that rebuilding process. It suggests a trajectory toward microrobotic systems that do not merely observe the microscopic world but actively manage it, with applications that could eventually span medicine, agriculture, environmental monitoring, and manufacturing at scales where human hands and conventional tools cannot reach.
It is worth noting what remains to be demonstrated before such applications become realistic. The current system operates in a laboratory setting with external power and control, and extending autonomy—onboard energy storage, decision-making, and robustness to unstructured environments—remains an open challenge across the field. The leap from 54 cilia in a fixed array to independently walking robots that communicate and coordinate in three dimensions will require advances in power delivery, wireless communication at small scales, and algorithms for collective decision-making under uncertainty. Nevertheless, the architectural template established here—sense the environment, communicate among units, actuate to reshape the environment, and repeat—provides a framework that future systems can inherit and extend, much as the individual capabilities demonstrated in the Cohen lab’s earlier work were combined in this study to produce something greater than the sum of its parts.
Subject of Research: For the first time, microrobots coordinate and control their environment
Article Title: For the first time, microrobots coordinate and control their environment
Article References: For the first time, microrobots coordinate and control their environment. (n.d.). Original publication
Image Credits: AI Generated
DOI: Not provided
Keywords: first, time, microrobots, coordinate, control, environment, scientific research
Cite Scienmag News
Bethany Barker. (October 17, 2026). Microrobots Sense Heat and Pump Fluids Together in a World First. Scienmag. https://scienmag.com/microrobots-sense-heat-and-pump-fluids-together-in-a-world-first/
Bethany Barker. "Microrobots Sense Heat and Pump Fluids Together in a World First." Scienmag, 17 October 2026, https://scienmag.com/microrobots-sense-heat-and-pump-fluids-together-in-a-world-first/. Accessed 17 October 2026.
Bethany Barker. "Microrobots Sense Heat and Pump Fluids Together in a World First." Scienmag. October 17, 2026. https://scienmag.com/microrobots-sense-heat-and-pump-fluids-together-in-a-world-first/


