

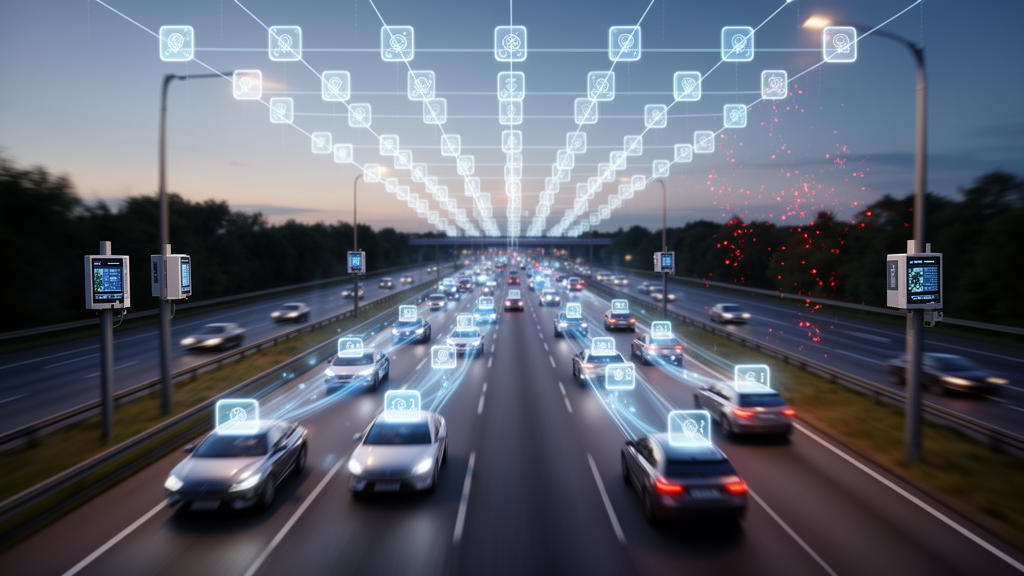
Self-driving cars and connected vehicles are no longer just modes of transportation; they are rolling data centers generating torrents of sensor readings, high-definition map updates, artificial intelligence inference requests, and infotainment streams that often exceed the computing capacity of the vehicles themselves. Vehicular Edge Computing, or VEC, has emerged as the leading architectural answer to this problem, pushing computation from distant clouds down to edge servers positioned at roadside units, base stations, and local access points. But the road is a merciless place for distributed computing. Vehicles travel at highway speeds, wireless links appear and vanish in seconds, and the network topology reshapes itself continuously as cars weave through dense urban canyons. A task that begins its offloading journey to one edge server may find its owner’s vehicle long gone before the computation finishes, forcing an interruption, a migration, or a complete failure.
A research team at the Shanghai Institute of Technology, led by Liqiong Chen together with Liubing Xiao, Xiaotian Chen, and Huaiying Sun, has now introduced a scheduling framework designed specifically for this chaos. The framework, called SPARCD, is described in the journal Cluster Computing and tackles what the authors identify as a stubborn weakness in the mainstream approach to vehicular task offloading. Most current systems rely on deep reinforcement learning to decide where and when to run each task, and the dominant algorithm in this space is Deep Deterministic Policy Gradient, better known as DDPG. DDPG excels at learning continuous control policies, but in the vehicular setting it suffers from high task interruption rates and slow convergence, because it makes offloading decisions largely blind to the future motion of the vehicles whose tasks it is scheduling.
The core insight behind SPARCD is deceptively simple: if the scheduler knows where a vehicle is going to be, it can avoid making decisions that will be invalidated by that movement. The framework therefore integrates three coordinated mechanisms into a DDPG-based learning pipeline. The first is a lightweight position prediction mechanism that incorporates vehicle motion state awareness and forecasts future locations, giving the policy a window into the near-term kinematic future of each vehicle. The second is an action masking mechanism, a technique borrowed from recent policy gradient research that restricts the agent’s action space to physically or logically valid choices at each decision point. The third is a state filling technique that enriches the observation vector so the neural network sees a complete and informative picture of the environment rather than a sparse or incomplete one.
To understand why these additions matter, it helps to consider what happens inside a conventional DDPG agent managing a VEC system. At each time step, the agent observes the state of the network, including queue lengths at edge servers, channel conditions between vehicles and access points, and the computational demands of pending tasks. It then selects an offloading action, perhaps assigning a task to a local processor, to a roadside edge server, or to a neighboring vehicle capable of cooperative computation. The problem is that the agent evaluates these choices using only current information. A link that looks strong now may dissolve in half a second as the transmitting vehicle rounds a corner or accelerates away from the access point. When that happens, the in-flight task is interrupted, its partial results are wasted, and the energy already spent on transmission and computation is lost.
SPARCD attacks this failure mode from multiple angles simultaneously. The position prediction component lets the framework estimate whether a vehicle will remain within effective communication range of a candidate edge server for the expected duration of the task. If the forecast says otherwise, the scheduler can steer the task toward a more durable option before committing. The action masking mechanism complements this by filtering out invalid or unsafe actions before they reach the policy network’s output layer, which both prevents the agent from learning from pointless experiences and accelerates convergence by shrinking the effective exploration space. The multi-objective formulation at the heart of the framework jointly optimizes three quantities that normally pull against each other: task latency, energy consumption, and reliability. Reducing latency often demands more transmit power, which raises energy use; maximizing reliability may require conservative offloading choices that increase delay. SPARCD balances these competing demands within a single scheduling model.
The authors validated the framework through simulations of typical urban scenarios, with vehicle densities of 30 vehicles per kilometer and task generation rates ranging from 0.5 to 1 task per second. The headline numbers are striking. Compared with a traditional DDPG algorithm operating in the same environment, SPARCD reduced the task interruption rate by 42.7 percent, cutting it from 18.2 percent to 10.4 percent. Average task latency dropped by 31.5 percent, falling from 3.2 seconds to 2.2 seconds. Perhaps most importantly from an engineering standpoint, these gains in speed and dependability did not come at a ruinous energy price: system energy consumption increased by no more than 7.9 percent, a trade-off the authors characterize as a significant overall performance improvement rather than a robbing of one metric to pay another.
The most demanding test came in high-dynamic conditions, where vehicles moved at 25 meters per second, roughly 90 kilometers per hour, a speed at which wireless connections to fixed infrastructure are fleeting and prediction windows shrink dramatically. Even here, SPARCD maintained a task completion rate of 82.3 percent. For comparison, a Q-learning based method, a simpler tabular reinforcement learning approach often used as a baseline, achieved only about 58.7 percent in the same scenario, meaning SPARCD outperformed it by more than 40 percentage points. The authors point to this result as evidence of the framework’s robustness and generalization ability in complex dynamic environments, suggesting that the learned policy does not merely memorize one traffic pattern but adapts across a range of mobility regimes.
The significance of this work extends beyond one benchmark. Vehicular edge computing sits at the intersection of several rapidly maturing technologies, including cellular vehicle-to-everything communication, roadside multi-access edge servers, and increasingly autonomous vehicles that cannot tolerate cloud round-trip latencies for safety-critical computation. Applications such as cooperative perception, where vehicles fuse sensor data to see around corners, and real-time navigation AI depend on offloading that is both fast and dependable. An interruption rate of 18 percent, which the baseline DDPG exhibited, would translate into a substantial fraction of these workloads failing or restarting, wasting bandwidth and battery resources in the process. Cutting that figure to roughly 10 percent while simultaneously lowering latency represents exactly the kind of systems-level improvement that makes edge-assisted driving applications practically viable.
Technically, the study also contributes to a broader conversation in the reinforcement learning community about how to make deep policies reliable in non-stationary environments. Action masking, highlighted in recent research on invalid action masking in policy gradient algorithms, has proven effective in games and robotics by preventing agents from selecting actions that are meaningless in a given state. Applying it to vehicular offloading, combined with mobility prediction, illustrates a general design principle: domain-specific structure can be injected into the learning pipeline to compensate for the brittleness of generic algorithms. Rather than waiting for the policy network to discover, through thousands of costly failed episodes, that offloading to a server the vehicle is about to drive away from is a bad idea, the framework encodes that knowledge architecturally.
The work arrives amid a wave of related research, including digital twin based offloading schemes, multi-agent deep reinforcement learning systems with trajectory prediction, and hybrid frameworks that combine transformer-style prediction models with reinforcement learning policies. Within that landscape, SPARCD distinguishes itself by treating mobility awareness, action validity, and state completeness as first-class citizens of the scheduling architecture rather than afterthoughts, and by quantifying the latency, energy, and reliability trade-offs under realistic urban traffic parameters. The authors, affiliated with the Department of Intelligent Technology at the Shanghai Institute of Technology and the Shanghai Engineering Research Center of Smart Energy, report no competing interests. As connected and autonomous vehicles continue to multiply on roads worldwide, frameworks like SPARCD point toward an urban computing fabric in which the movement of traffic is not an obstacle to computation but an input the scheduler can anticipate and exploit.
Subject of Research: Multi-objective task offloading scheduling in vehicular edge computing using deep reinforcement learning with mobility prediction
Article Title: SPARCD: a multi-objective cooperative scheduling framework for vehicular edge computing
Article References: Chen, L., Xiao, L., Chen, X., & Sun, H. (2026). SPARCD: a multi-objective cooperative scheduling framework for vehicular edge computing. Cluster Computing, 29(15), Article 844. https://doi.org/10.1007/s10586-026-06655-z
Image Credits: AI Generated
DOI: 10.1007/s10586-026-06655-z
Keywords: vehicular edge computing, task offloading, DDPG, deep reinforcement learning, action masking, position prediction, multi-objective optimization, task interruption, latency reduction, energy consumption, Internet of Vehicles, edge servers
Cite Scienmag News
Marilyn Langley. (October 17, 2026). Smart Scheduling Framework Cuts Task Interruptions in Vehicular Edge Computing by Nearly 43 Percent. Scienmag. https://scienmag.com/smart-scheduling-framework-cuts-task-interruptions-in-vehicular-edge-computing-by-nearly-43-percent/
Marilyn Langley. "Smart Scheduling Framework Cuts Task Interruptions in Vehicular Edge Computing by Nearly 43 Percent." Scienmag, 17 October 2026, https://scienmag.com/smart-scheduling-framework-cuts-task-interruptions-in-vehicular-edge-computing-by-nearly-43-percent/. Accessed 17 October 2026.
Marilyn Langley. "Smart Scheduling Framework Cuts Task Interruptions in Vehicular Edge Computing by Nearly 43 Percent." Scienmag. October 17, 2026. https://scienmag.com/smart-scheduling-framework-cuts-task-interruptions-in-vehicular-edge-computing-by-nearly-43-percent/


